ENTRY
13
October 14, 2026
Shooter Mounting, Wiring Cleanup & Strafing Fixes
Meeting Summary
We didn't take the robot apart today, woohoo! We mounted the shooter, moved the intake motor to a sturdier spot, fixed the intake gears, and organized all of our wiring into protective tubing. We found two reasons the robot wasn't strafing correctly: the wiring was incorrect, and the front wheels had been put back on wrong when we resized the frame. Sarah made a wiring diagram, redesigned the guard plates, and planned a swappable alliance number plate. We also discussed sensors and how to use our camera to judge distance.
Build: Shooter & Intake
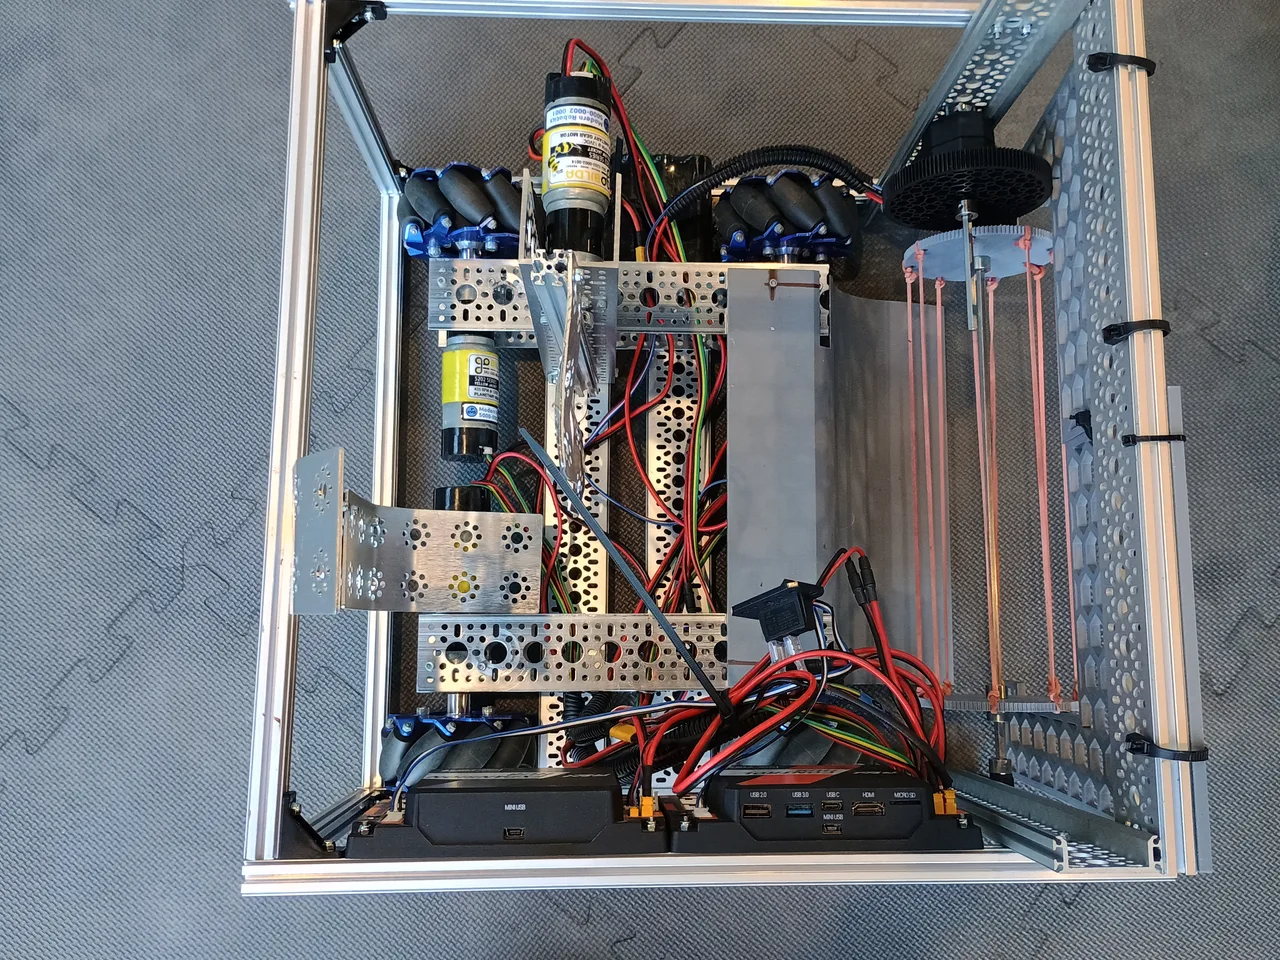
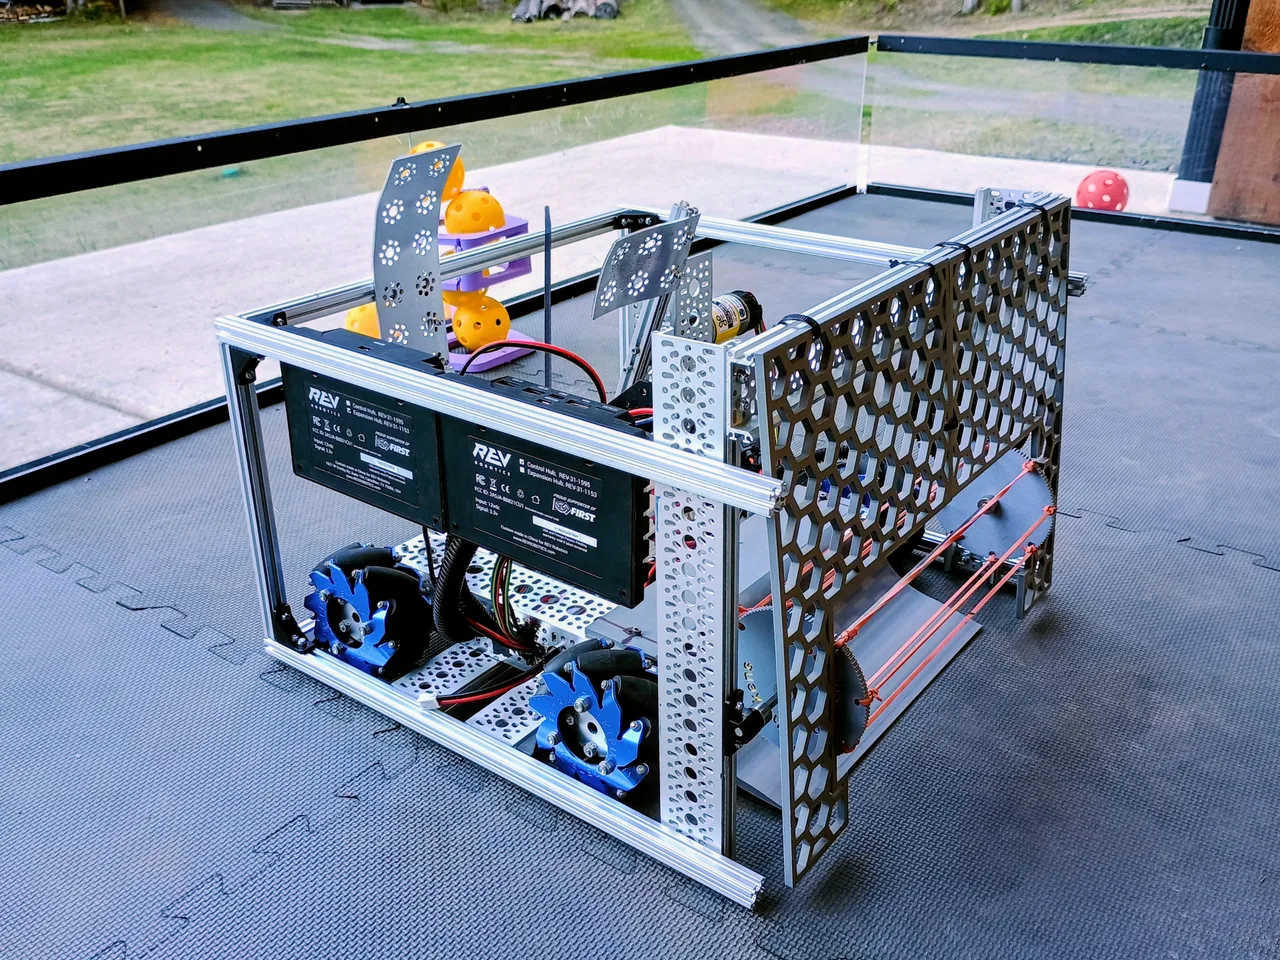
- Mounted the shooter on the robot
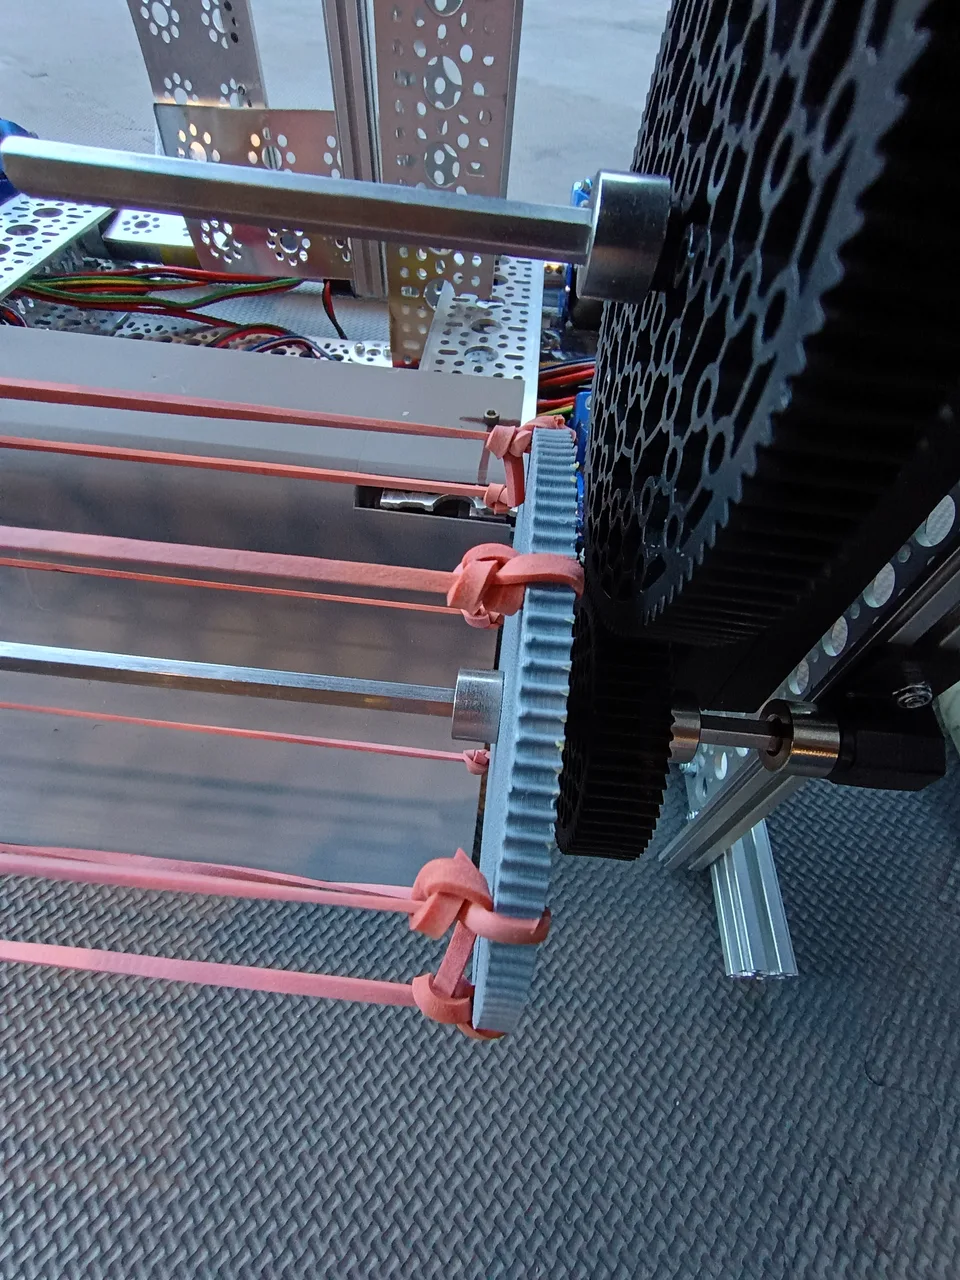
- Moved the motor that drives the intake to a more permanent, sturdy location. Before, it was flexing around and wasn't stable.
- The intake gears were meshing too close together and didn't fit correctly, so Josh fixed the gear spacing
- The intake was too high: it rubbed against the plates, and the pollen balls had a hard time going in. But if we lowered it where it was, the nectar balls wouldn't fit, so the intake also needed to move outward. After making sure the robot would still be within the size limits, we moved the front support bars outward so we could lower the intake.
- Josh took measurements of the shooter and the shooter's guiding ramp
Build: Intake Ramp
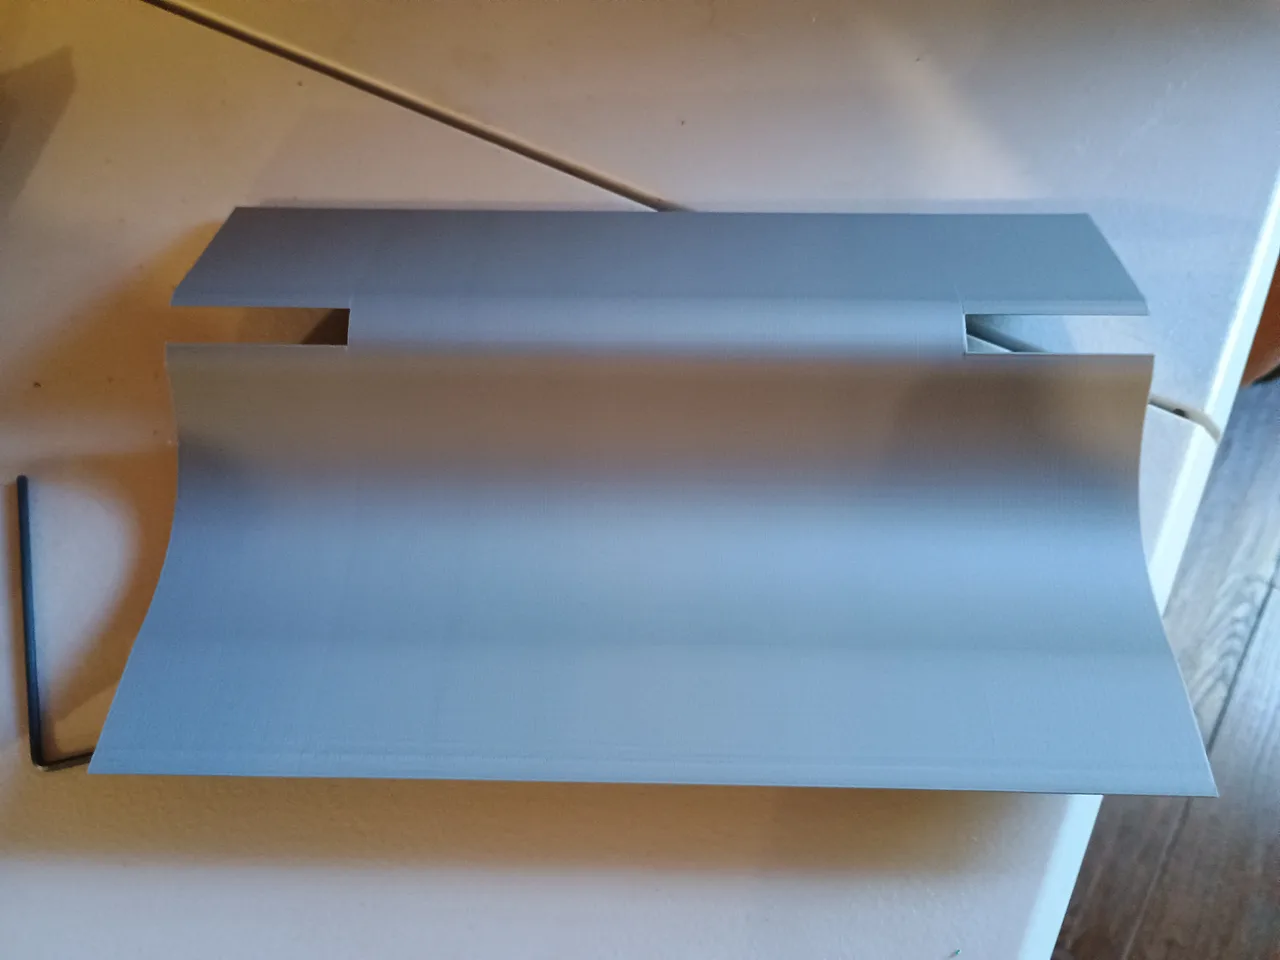
- Josh redesigned the intake ramp and sent the file to Sarah to print
- We decided not to build the shooter guiding ramp for now, because Josh realized the design wasn't going to work
Wiring
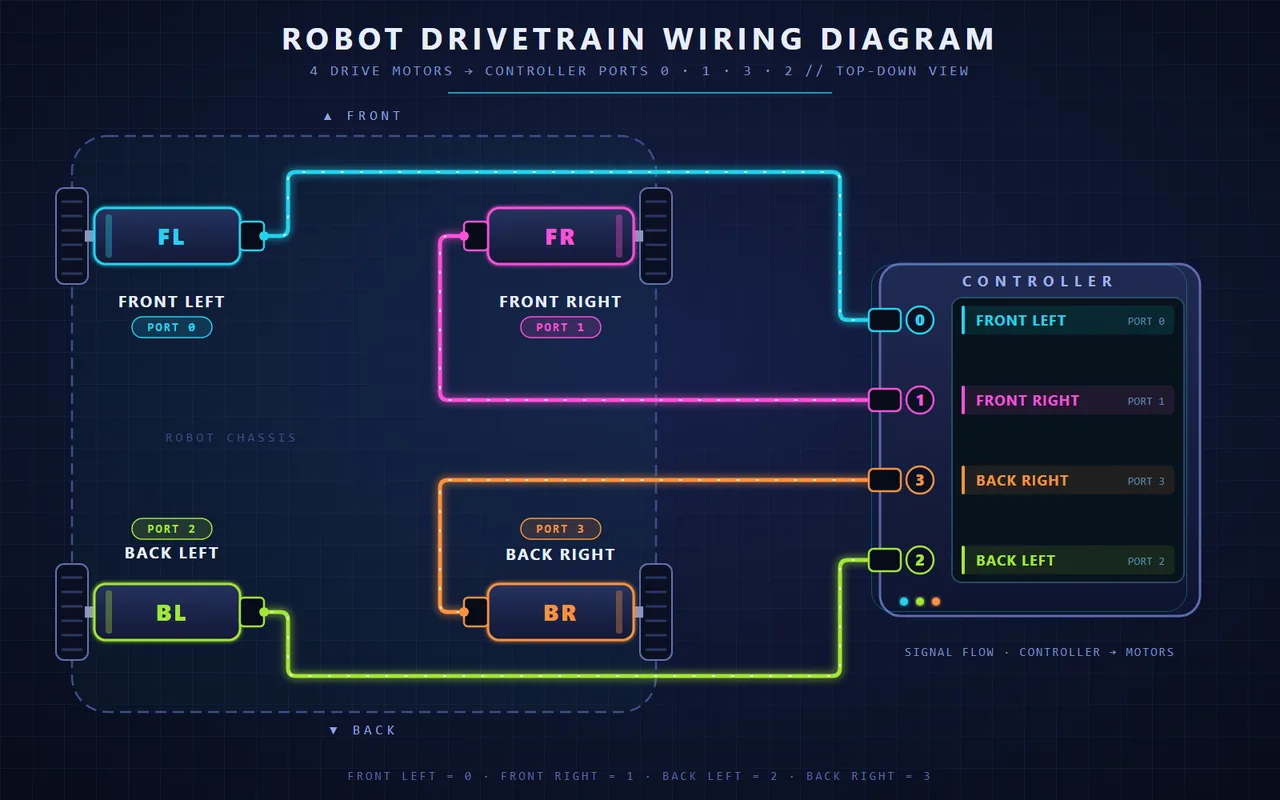
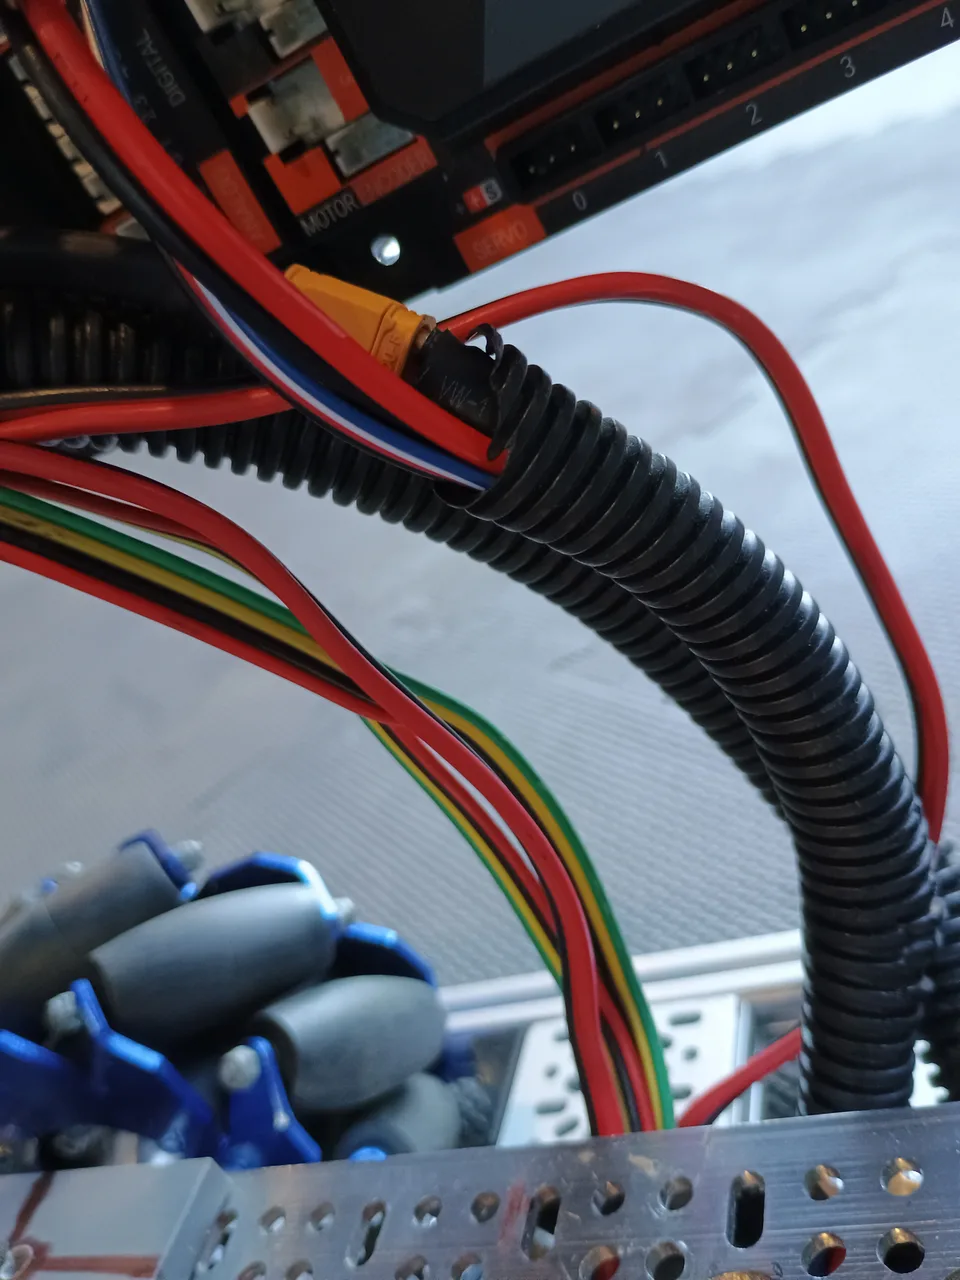
- We realized today that our wiring was incorrect, which is probably why the robot wasn't strafing correctly at our last meeting
- Sarah made a wiring diagram with Claude, based on a sketch by Torin, showing which controller port each drive motor plugs into
- Arranged the wires so they're out of the way of all the mechanisms, and Torin put them in protective tubing so they can't get caught or tangled
- Moved the battery to the other side of the robot to give us more room
Drivetrain & Code Issues
- When we took the robot apart to resize the frame, we accidentally installed the two front wheels the wrong way, so we have a strafing problem again. Next meeting, we'll flip the two front wheels back around.
- The intake runs in reverse again. It's an easy fix in the code, and Sarah will fix it.
Guard Plates & Alliance Number
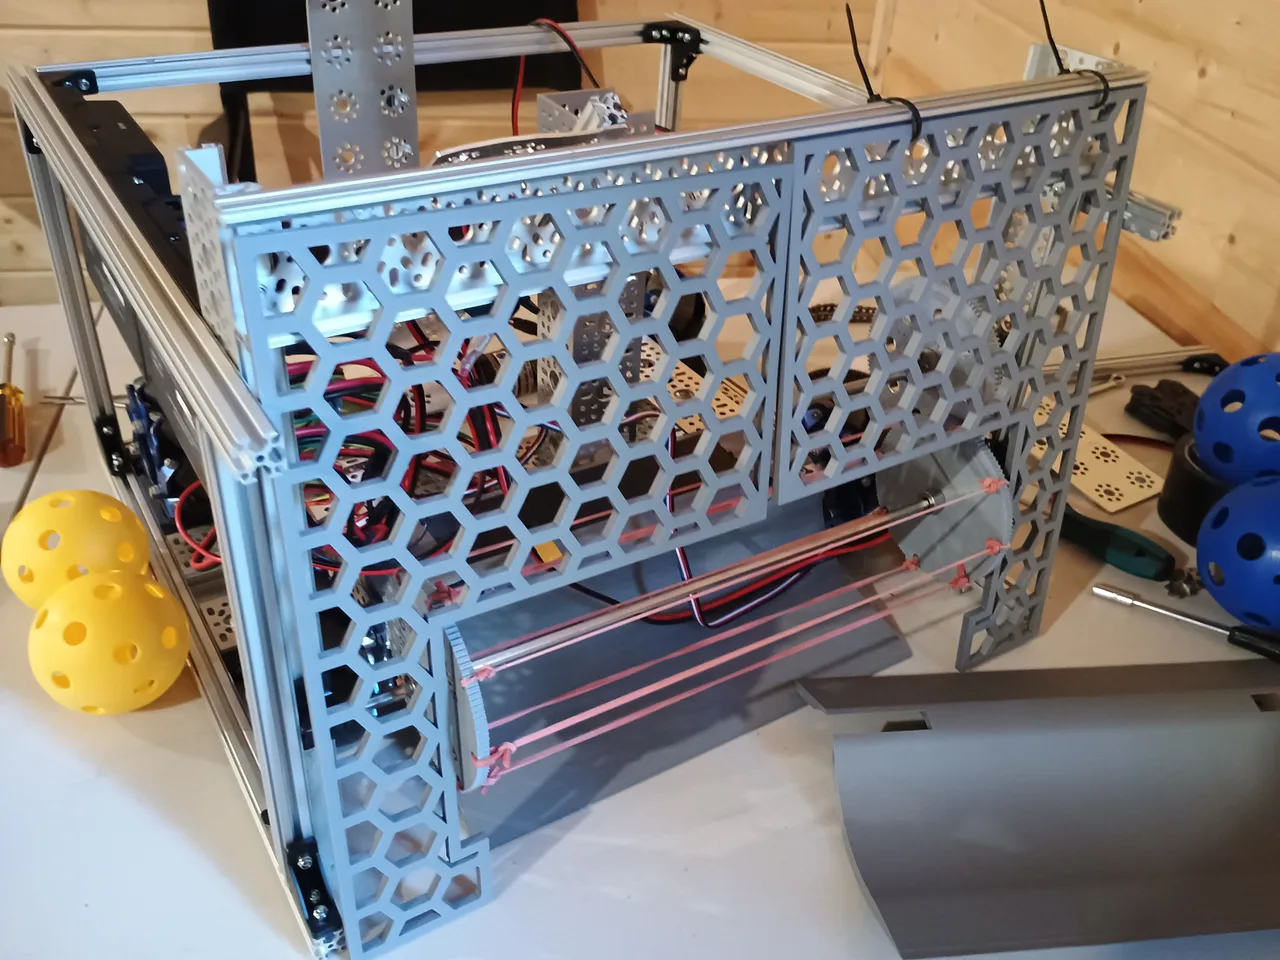
- Sarah redesigned the guard plates and cut all of them in half so they fit on the printer. Last time, she had only cut one file in half for a quick test print.
- Sarah researched the rules for the size and specifications of the team number on the robot
- We decided to add a slot where we can slide in a rectangle in our alliance color with 3D-printed white numbers, so we can swap it depending on which alliance we're on
Game Field Mock-Ups
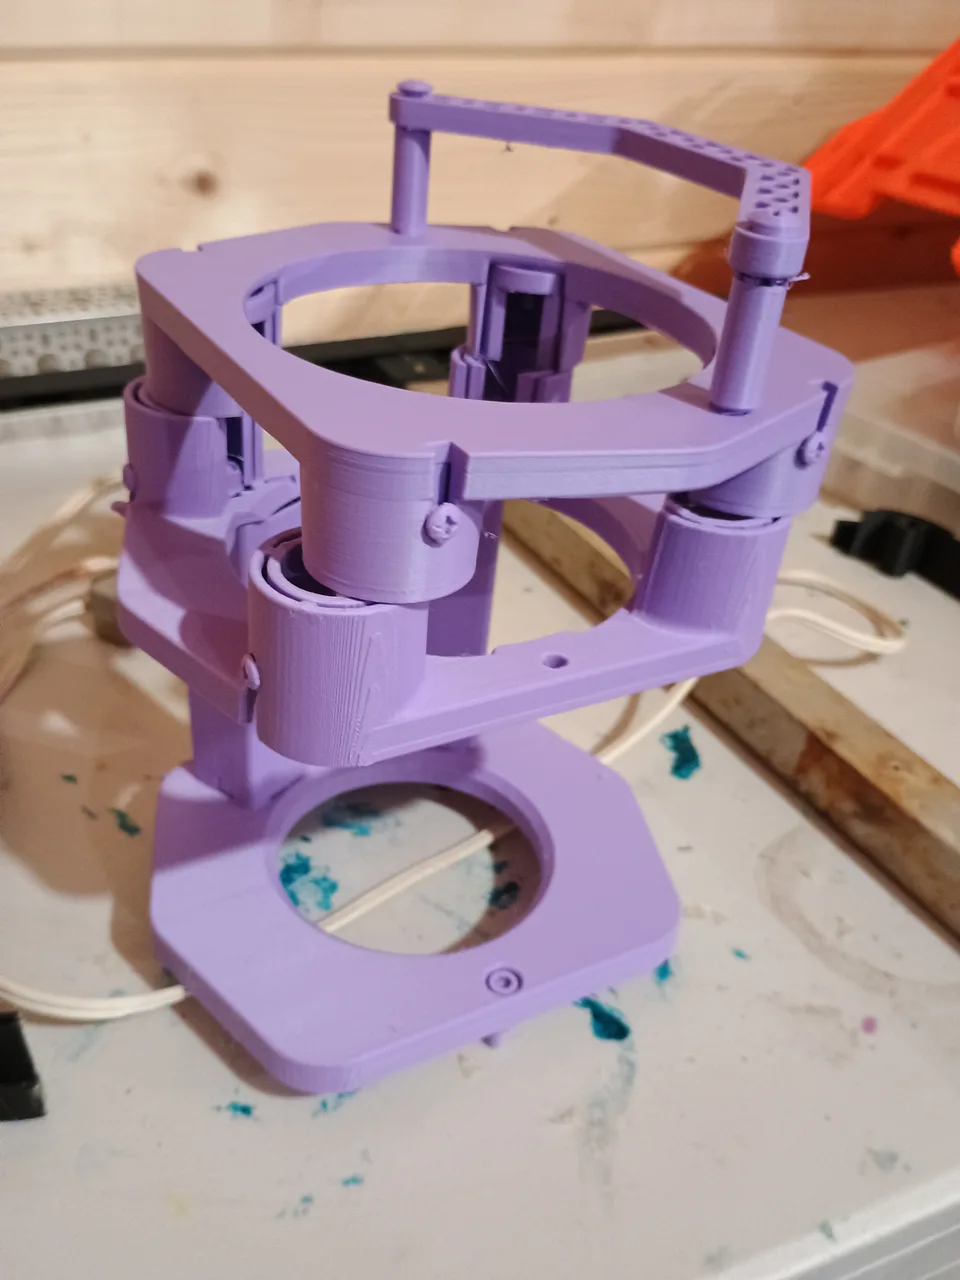
- Josh printed the flower
Sensors Discussion
- Discussed using distance sensors and color sensors
- Talked about programming the camera to estimate distance by calculating the ratio between how big an object looks and how far away it is
Website & Claude
- Sarah had to uninstall Claude for a test and reinstall it afterward, and some of her chats were lost. These were important chats about the guard plates, gears, code, and website, so she looked up how to recover them and got them back.
- Sarah added last meeting's notebook entry and the new About the Team page, with a section about our robot, to the website
- Because last meeting's entry wasn't on the website yet, Torin and Josh couldn't check their homework there, so not all of it got done
Homework Check-In
- Josh: printed the flower and redesigned the intake ramp. Still to do: finish printing the hive frame and visit Video Games Plus.
- Torin: looked up the scrimmage start and check-in times, but they aren't posted yet, so our coach will get that information. Still to do: return the aluminum, and install CAD on his mom's computer to start a flap prototype.
Planning
- We'll probably have another all-day meeting on Saturday, October 17, from 9 AM to 5 PM
- We're debating whether to give each business that donates a thank-you card, but we're worried we won't be able to keep up
Homework / Action Items
- Josh: visit Video Games Plus before the scrimmage to say thank you and ask about using their logo; finish printing the hive frame; send his info for the About the Team page on Telegram
- Torin: return the aluminum; install CAD on his mom's computer (if she agrees) and start a flap prototype; send his info for the About the Team page on Telegram
- Sarah: go to Cascade before the scrimmage to say thank you and ask about using their logo; add a gallery page to the website; keep printing the robot walls; print the remaining small hive frame pieces; fix the reversed intake in the code; edit this entry and upload it to the website
- Coach: get the scrimmage start and check-in times once they're posted
- Next meeting: flip the two front wheels back around
This notebook was created with the assistance of Claude AI and Handy dictation software.