ENTRY
22
November 9, 2026
Shooter Testing, Stacked Flywheels & Gate Servo Fix
Meeting Summary
We raised the intake and shooter and tested the shooter for the first time since the rebuild. Each ball size hit the same spot every time, but the pollen shot low and the nectar shot a little higher than the hive. We turned down the power and stacked a second set of flywheels. Sarah got the gate servo working in the code, and Josh will redesign the intake ramp so both ball sizes hit the flywheels in the right spot.
Build
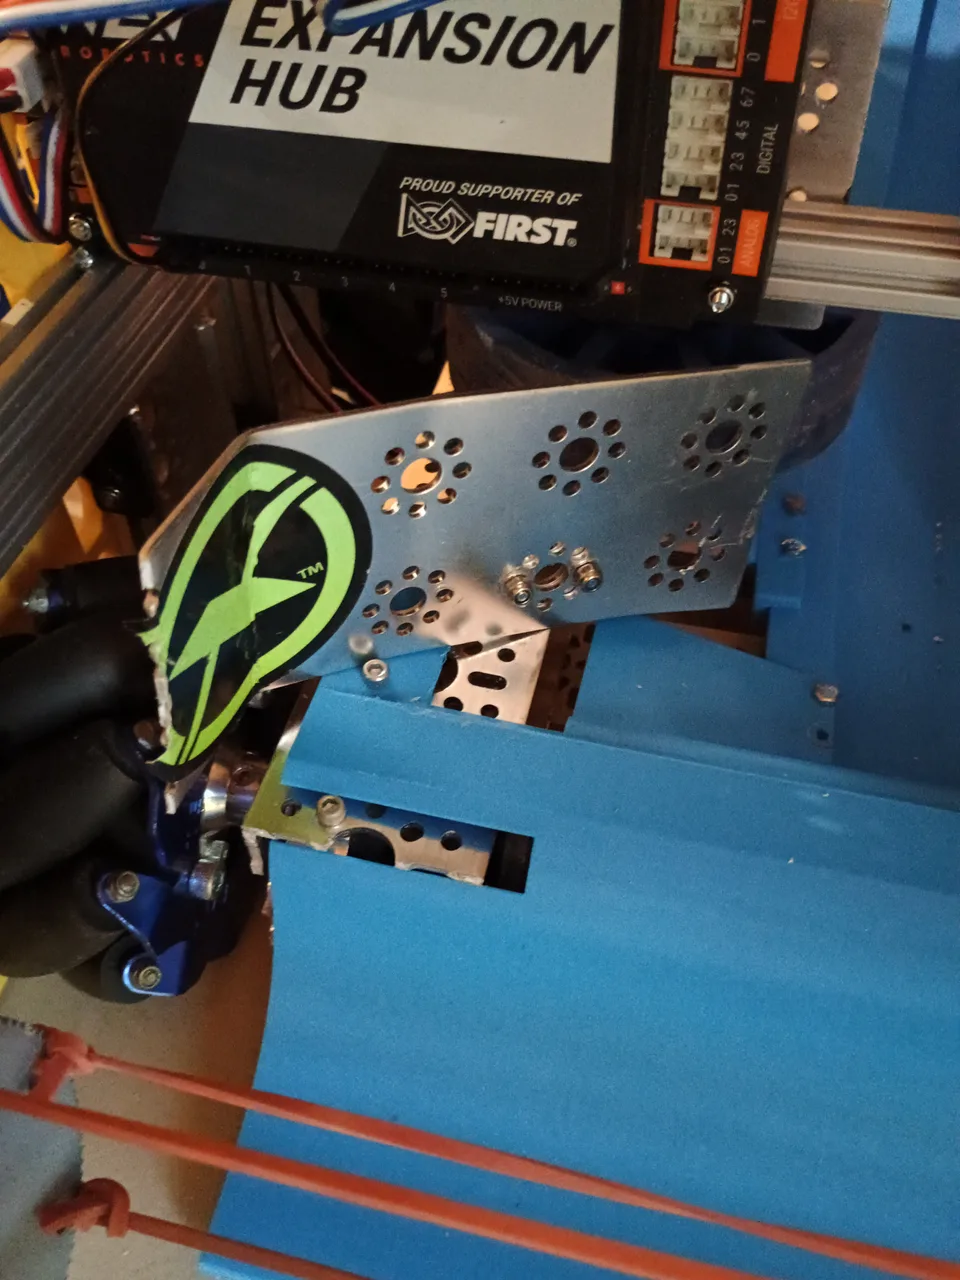
- We remounted the side plates so we could move the intake higher. This makes the robot sturdier and raises the shooter.
- We added metal guides inside the robot to guide the balls and make sure too many can't fit inside
- We realized we had put on the wrong power switch, so we put our old one with the cover back on
Shooter Test
- The nectar balls were hitting the center of our double flywheels, but the smaller pollen balls weren't
- The pollen came out pretty low, but it hit the same spot every time
- The nectar went a little higher than the hive will be
- We turned the power down from 0.8 to 0.5, but didn't have time to test it
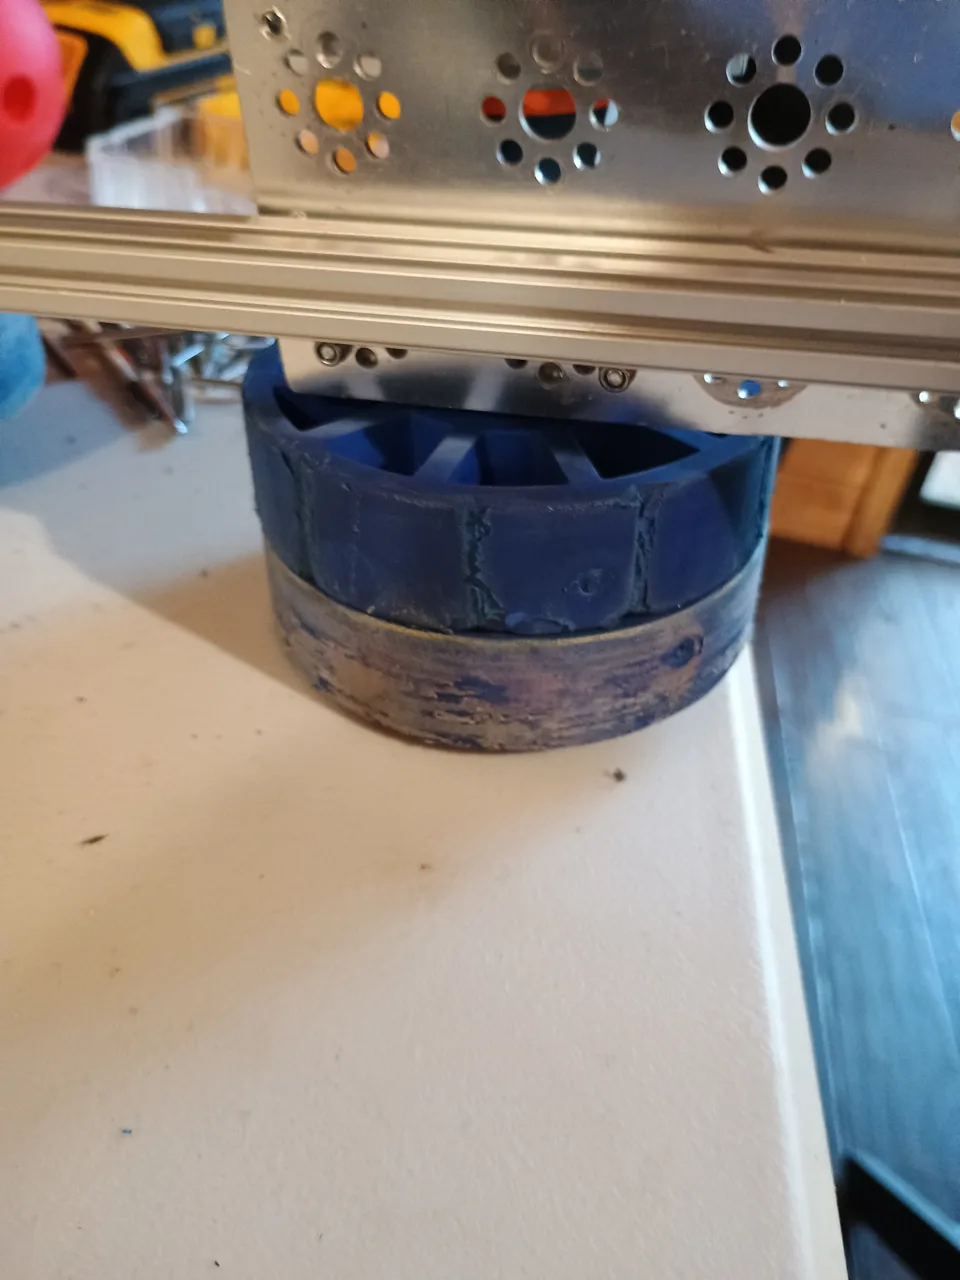
- We stacked a second wheel on each flywheel. The bigger gripping area means both ball sizes can hit near the center of the wheels.
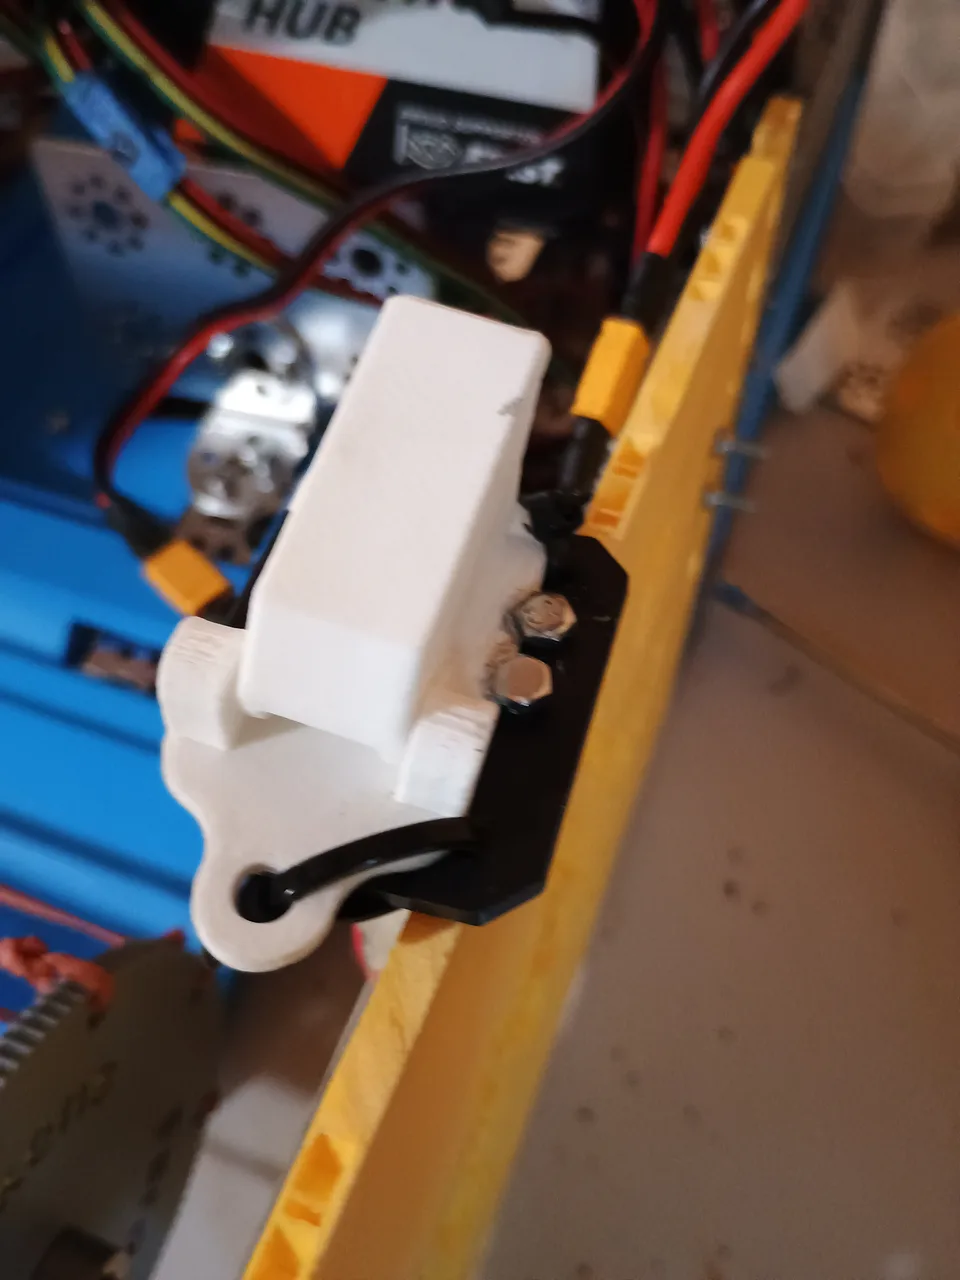
- The nectar balls broke one of our 3D-printed support brackets for the shooter ramp because the motors needed to be moved, so we replaced it with a spare
- Result: we think the test was very successful. 9 out of 10 balls hit within a few inches of each other, for both the yellow balls and the blue and red balls. The two sizes landed at very different heights because of the flywheel spacing. We can bring them closer together by adjusting the flywheel spacing, wheel height, and motor power, and trim the ramp if we need to.
Intake Ramp Redesign
- The intake ramp drops the balls too low, so the pollen still won't hit the flywheels well, even with the stacked wheels
- Josh took measurements and will redesign the ramp so it slopes down into the shooter and both ball sizes hit the flywheels in the right spot
- This will be our ninth ramp iteration! We'd like to put all of our 3D-printed iterations in a bucket to show how our design changed.
Programming
- Sarah changed the shooter to hold and press controls
- The gate servo wasn't moving at all. Sarah ran the shooter test, replaced the servo, made a gate test, and renamed the servo from "loader" to "gate" in the code.
- It still wasn't moving, so we asked Claude for help. The gate needed to be on gamepad 1, and once we switched it, it worked.
- Sarah made sure the arm was attached in the right position when the servo is at zero
- We originally planned for the gate to open, let all the balls through, and then close. Now it will move back and forth so we don't dump a bunch of balls on the shooter at once, which slows the flywheels down.
- The intake was programmed as a basic DC motor, so we changed it to an HD Hex UltraPlanetary motor, which might make it faster. We have different opinions on whether the intake should go faster or slower, so we'll see.
Getting Ready for League Meet 1
- Josh and Sarah reorganized our competition bin and started moving some things into a new bin. We'll finish on Wednesday.
- We printed our team roster and the robot inspection checklist, and we'll go over them on Wednesday or before the meet
- We're planning a long session on Wednesday, from 2 to 7 with snack breaks, to really focus on the shooter: adjusting the flywheel spacing and angle, and testing the new power
- Torin will try to finish the portfolio draft for the meet, but there's still a lot to make clear
- Josh thinks he fixed his 3D printer
- Charge the batteries. ABC: Always Be Charging!
Homework / Action Items
- Josh: redesign the intake ramp and send it to Sarah
- Torin: make a new list of what to take to the meet on Saturday (or find the old one); try to finish the portfolio draft
- Sarah: print Josh's redesigned intake ramp; edit this entry and upload it to the website
- Coach: contact Video Games Plus; get googly eyes for the robot
This notebook was created with the assistance of Claude AI and Handy dictation software.