ENTRY
20
November 2, 2026
Planning Day: Robot Drafts, TPU Test & Meet Goals
Meeting Summary
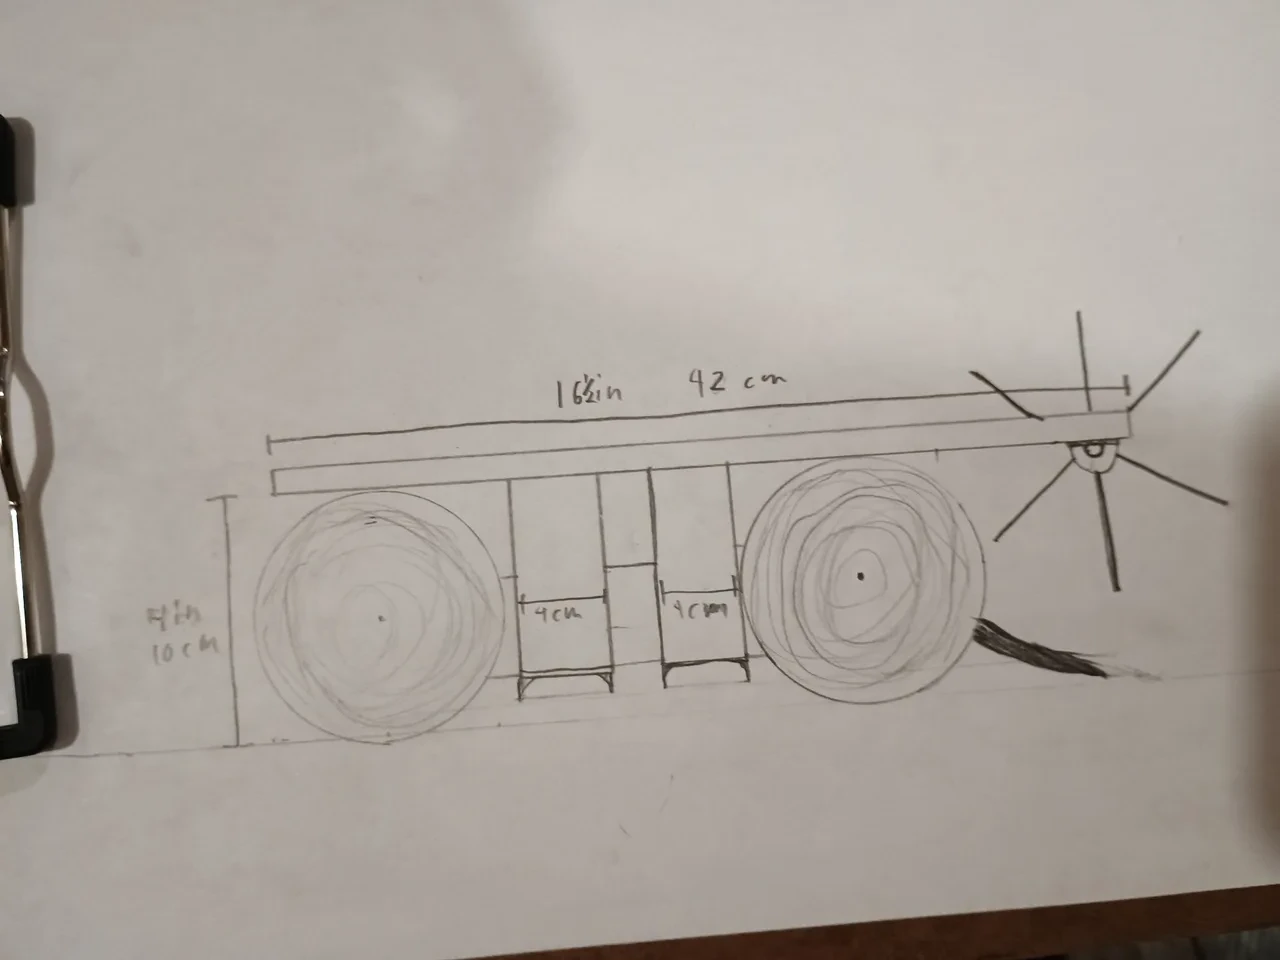
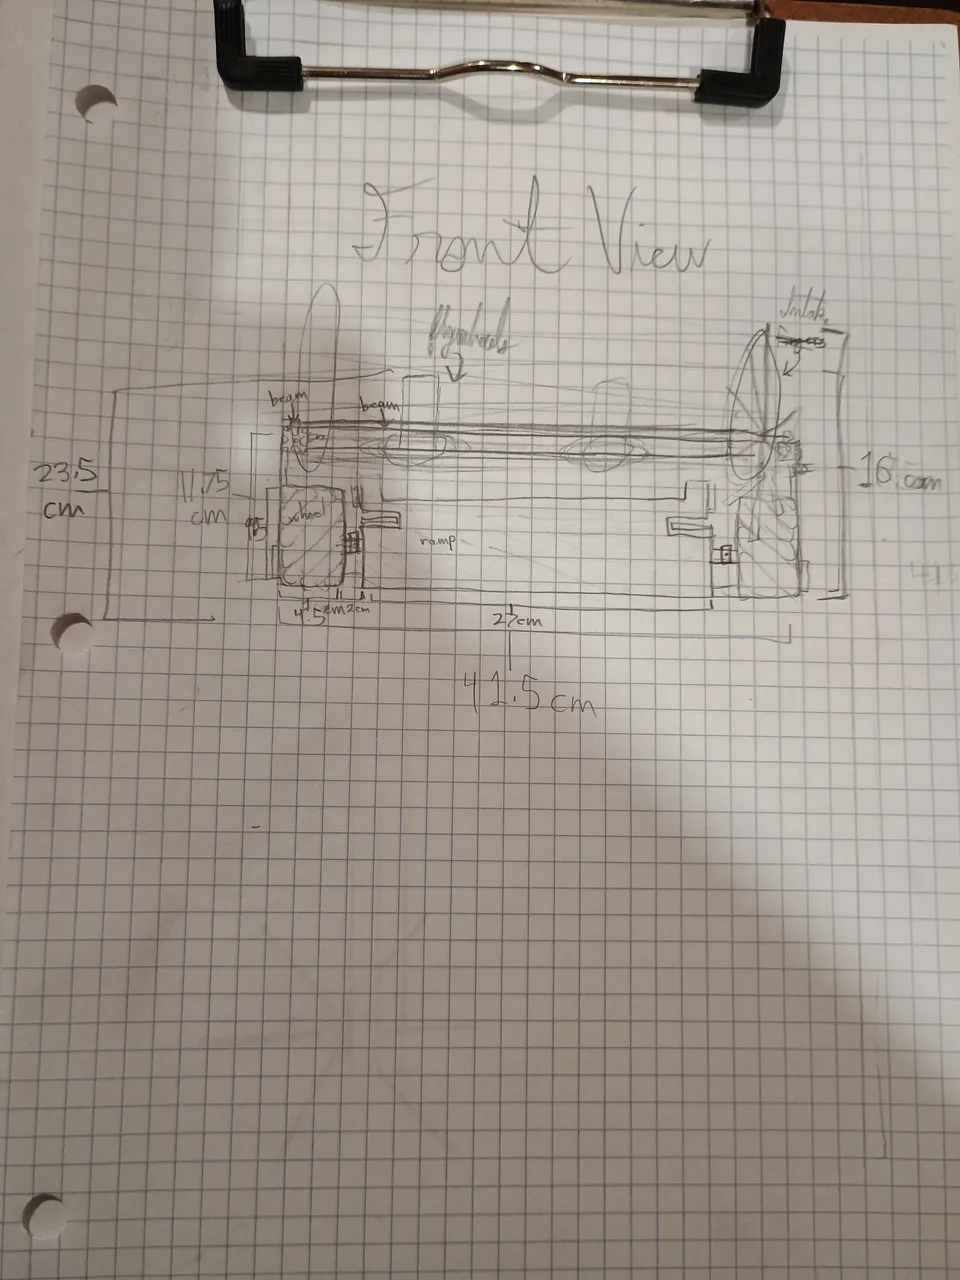
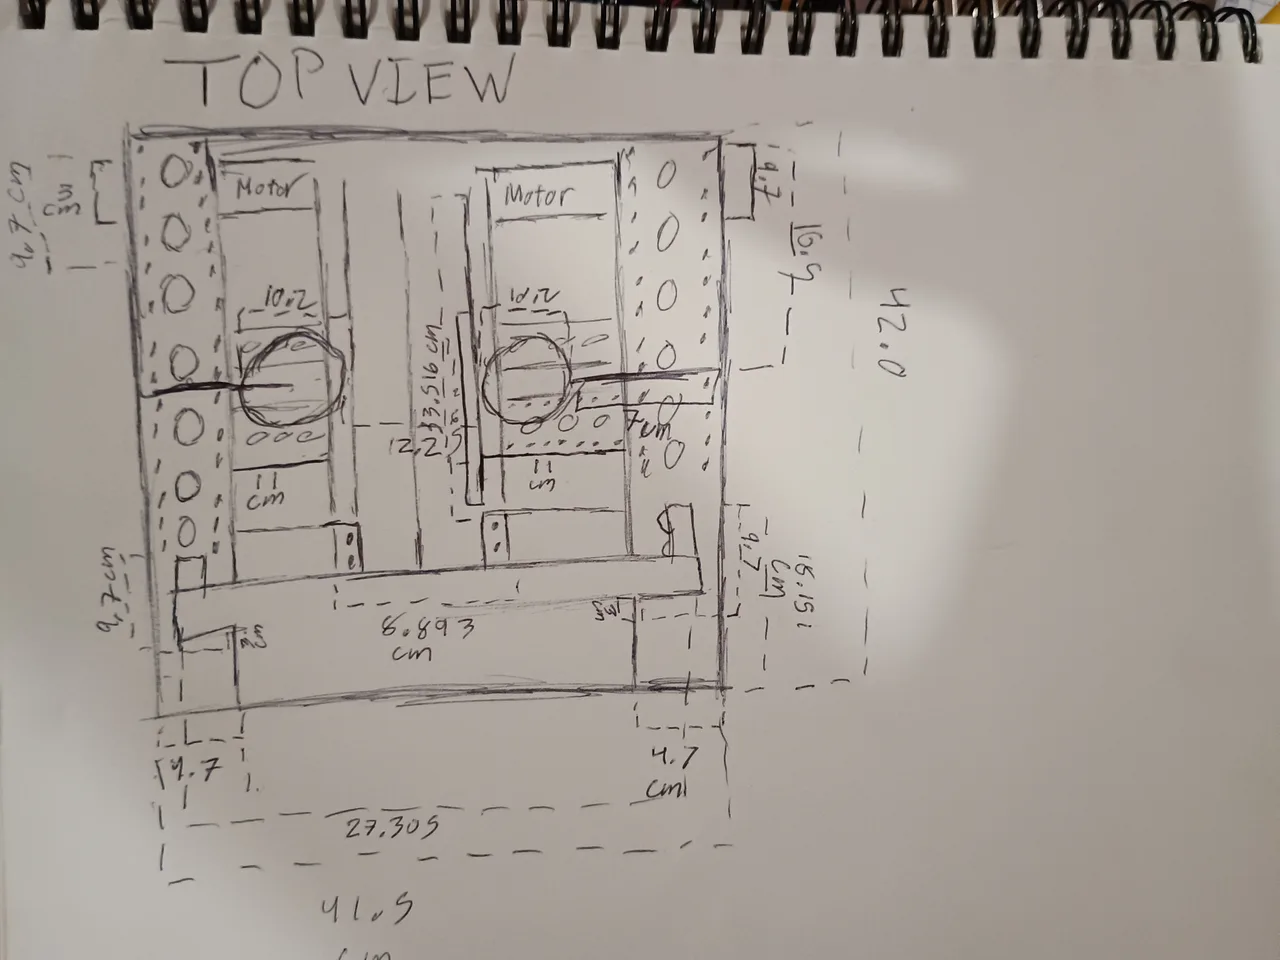
This was mostly a planning day. We drafted our robot on paper with all of its dimensions, so we can check where new parts will fit before building them. We tested the TPU intake fingers, mounted the shooter wheels, designed a servo arm to hold balls until the flywheels are up to speed, and set our goals for League Meet 1.
Drafting the Robot
- We sketched the robot from the front, top, and side, with all the dimensions
- This helps with spatial awareness: we can see where everything goes without going through a bunch of build iterations
- When we want to add something, we can check our drawings first to see whether it fits or what we'd have to modify
TPU Finger Test
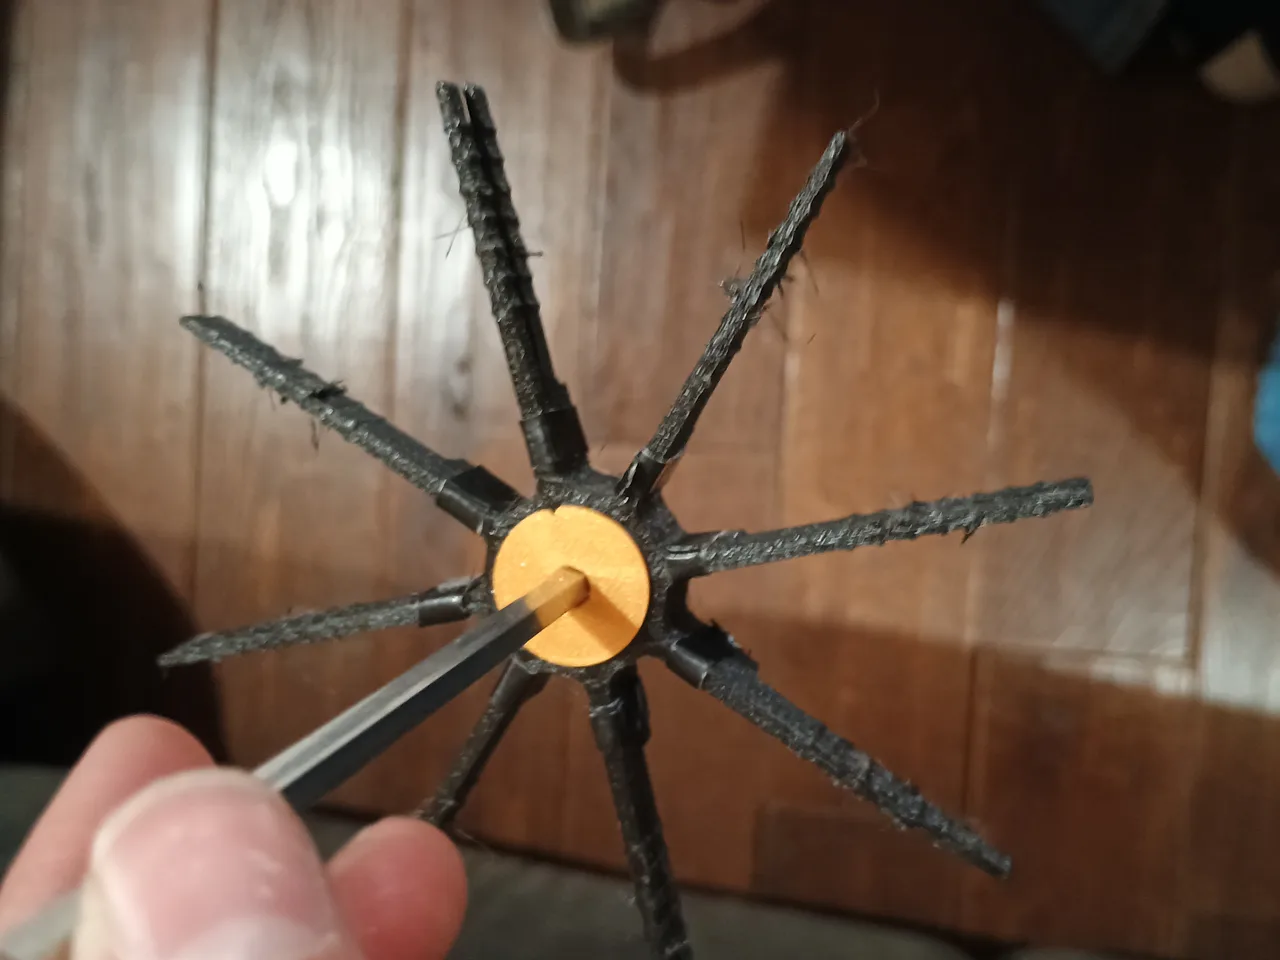
- Sarah started printing three finger sets at once, but decided to make sure everything fits and works before printing the full parts
- She stopped the print a third of the way through and taped the three pieces together, since that matches the thickness of the real finger
- The fingers were way too stiff. We cut off one of the three layers, but they were still too stiff.
- The fingers slipped at first. We thought the tape might be causing it, and taking some of the tape off helped a little.
- Sarah also printed a hub quickly during the meeting, since Josh's printer is broken
- Decision: we'll keep the rubber band intake for the upcoming meet so we can focus on the shooter, and add a guard over it so other robots can't get into it
- Sarah will have to redesign the fingers at some point so they're more flexible
Ramps & Shooter Guide
- Sarah printed Josh's redesigned intake ramp, which we're keeping for now
- Josh redesigned the shooter ramp during the meeting and shortened it so it fits inside the robot
- Instead of a tube, the shooter will use guide rails. The force from the flywheels should be enough that we don't need a full tube.
- Josh is sending Sarah the brackets that attach the shooter ramp to the walls, and Sarah will print two of them
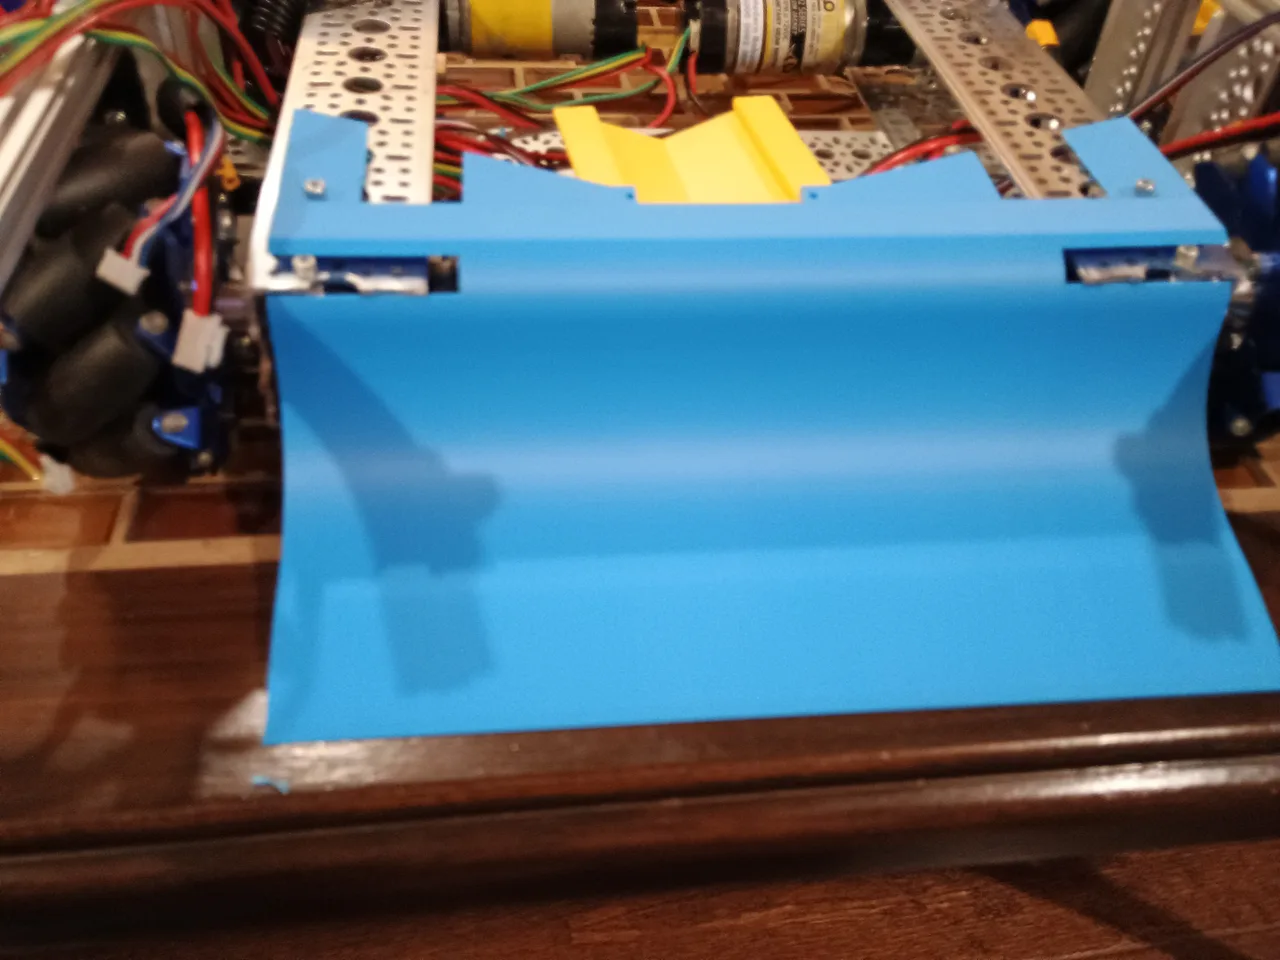
Build: Frame & Shooter
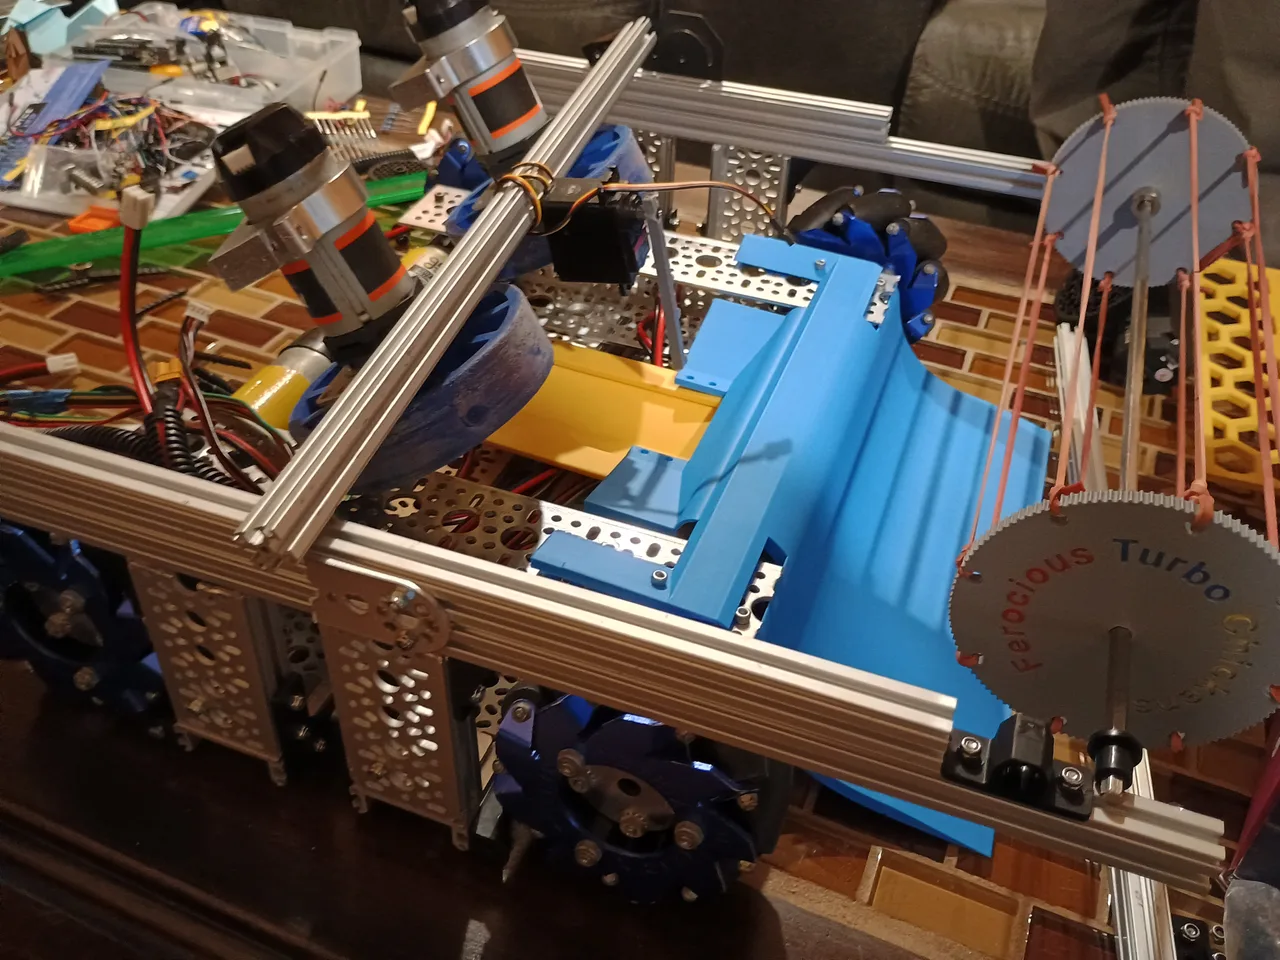
- Torin kept building the frame
- Josh worked on mounting the shooter wheels
- For now, we'll make simple cuts for the guard plates and mounting plates. They don't have to look pretty yet, and we're running out of time before the meet.
Servo Arm for Loading
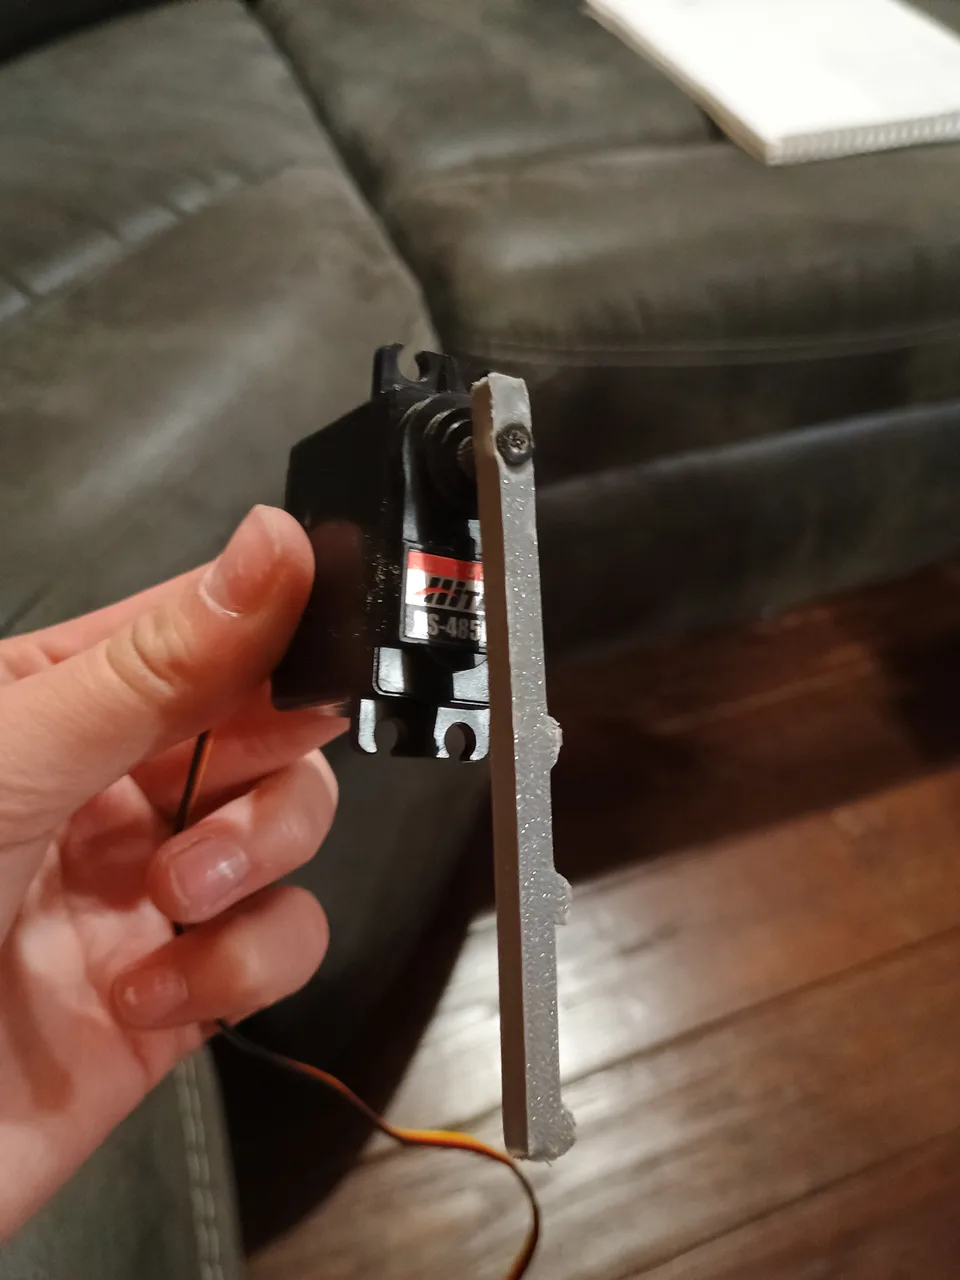
- Sarah worked on a servo arm that holds the balls back so they don't reach the flywheels too early. The flywheels need about a second to build up speed before a ball touches them.
- Sarah originally planned for the arm to move up and down between the flywheels. Torin suggested moving it side to side, and Sarah realized that would work a lot better.
- To make the ball stopper, Sarah cut a piece off one of our guard plates
Goals for League Meet 1
- Get at least one hive tip
- Dial in our shooter: at least 7 out of 10 shots into the hive. Our real goal is 10 out of 10, but 7 out of 10 would make us happy for this meet.
- Not for this meet: the TPU intake, a color sensor, or an automated turret shooter
Checklist & Portfolio
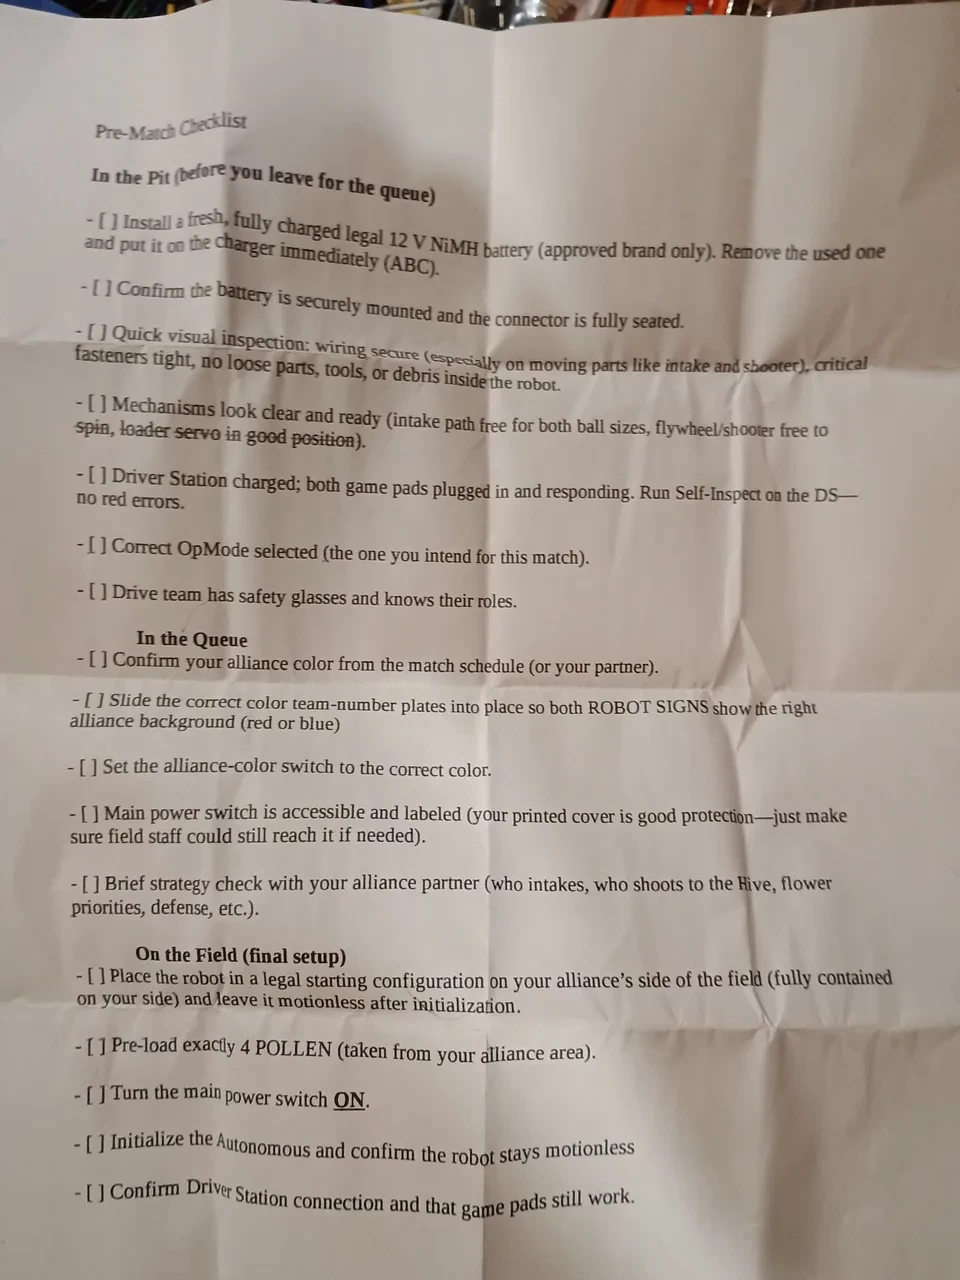
- Torin made our pre-match checklist of robot checks to do before every match
- Torin went through the whole portfolio and edited it, but the computer crashed and his edits were lost, so he'll keep working on it
Outreach & Planning
- Josh and our coach visited Video Games Plus on Wednesday, but the people who make the decision weren't there, so our coach will email them
- We'd like to do another all-day session before the meet, if it works out
- We want to do more outreach, get our banner printed, and bring in more funding
- We'd like experts to come look at our robot, probably after the next league meet
Homework / Action Items
- Josh: send Sarah the mounting bracket file; fix his 3D printer
- Torin: keep editing and working on the portfolio
- Sarah: print the shooter ramp and two mounting brackets for it. At some point, go through all of our code, edit it, and get familiar with it, and redesign the TPU fingers.
This notebook was created with the assistance of Claude AI and Handy dictation software.