ENTRY
15
October 19, 2026
Flywheel Shooter, Code Fix & First Hive Shots
Meeting Summary
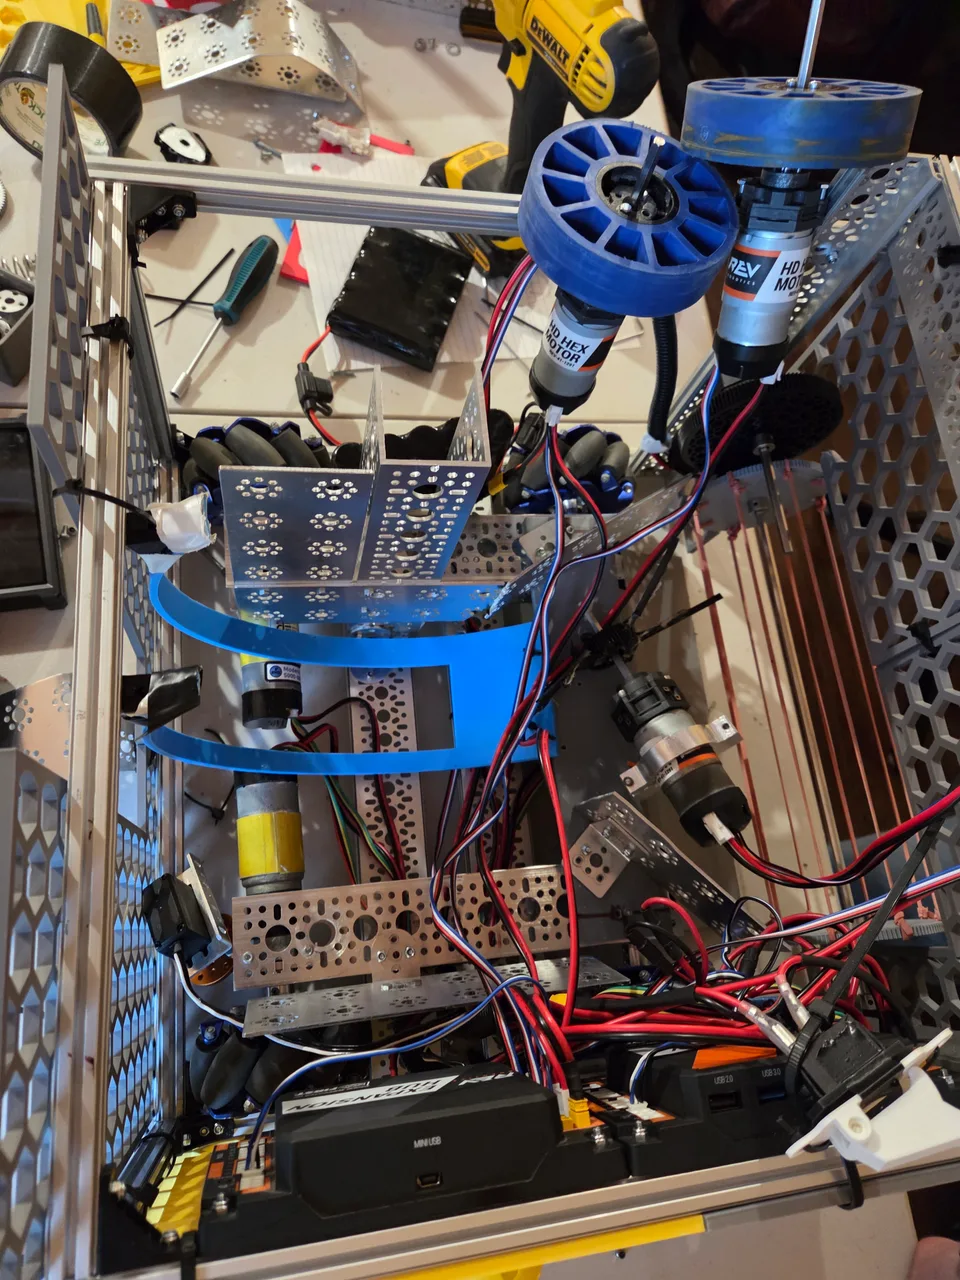
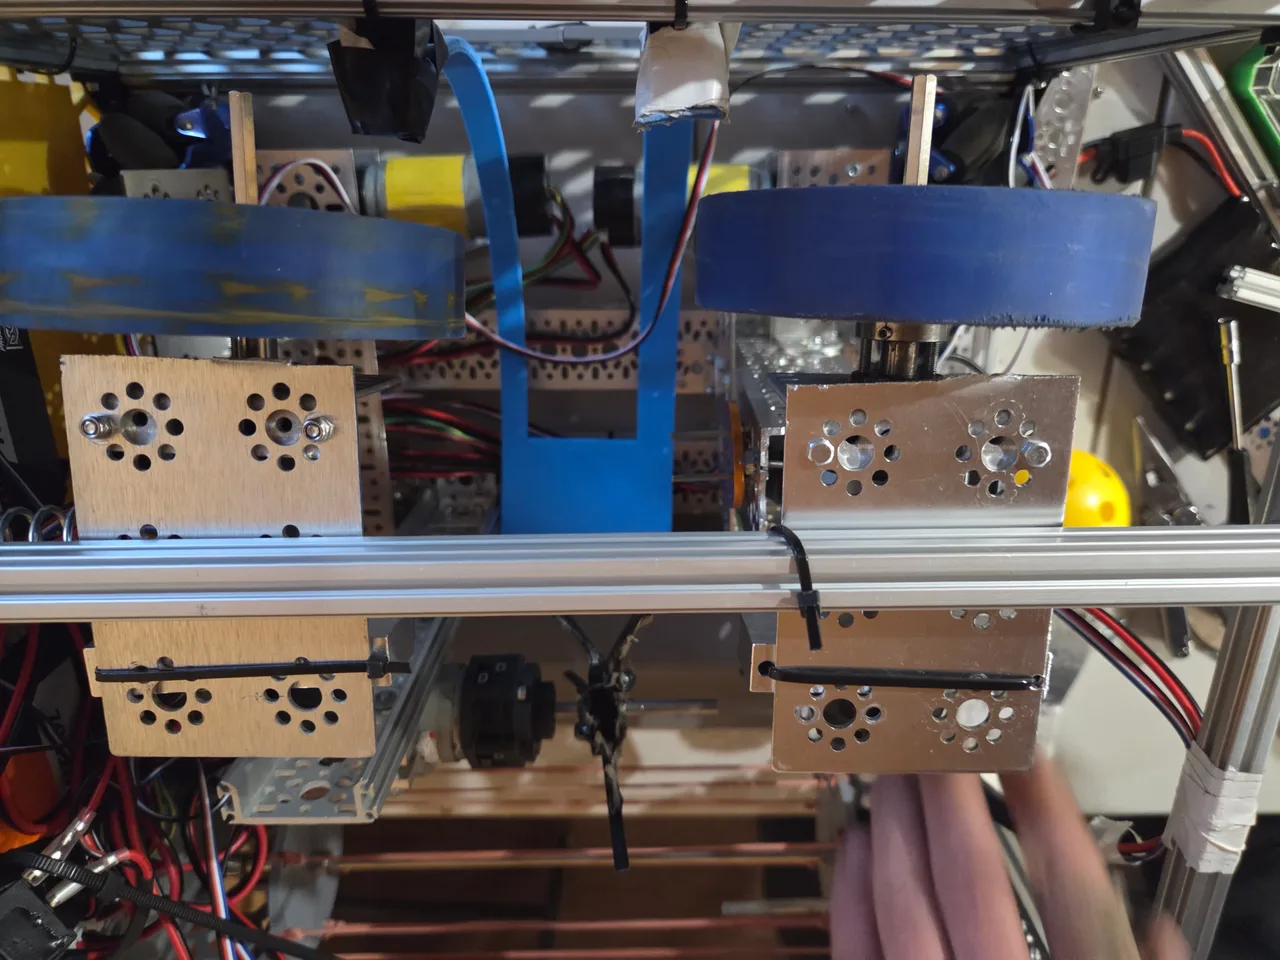
We spent most of the meeting on the shooter and the whole ball path after the intake, which went through many iterations. We switched to a double flywheel shooter, changed how balls load into it, and found and fixed a code problem that was keeping the flywheels slow. Once they ran at full speed, the balls flew all the way to the ceiling! After tuning the power and adjusting the robot's angle and position, we finally hit our mock-up hive.
New Ball Path
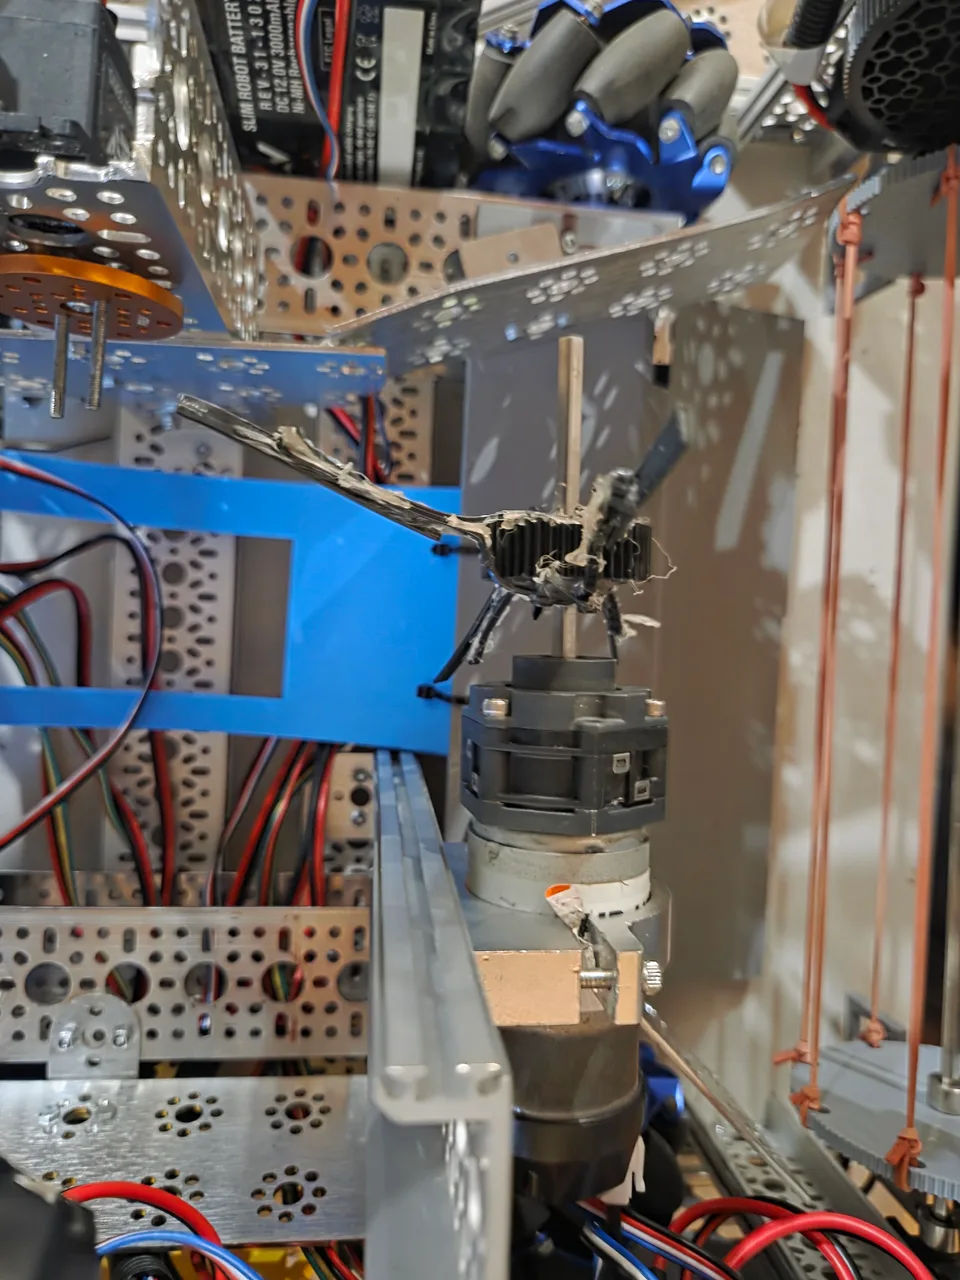
- Balls now load from the front, and the catapult scoops them up to the flywheels
- Removed the spinning feeder wheel with the zip-tie "fingers" and the kicker
- The servo that ran the kicker now runs the catapult
Flywheel Motors
- We started with two Yellow Jacket motors, but they weren't shooting the balls high enough. We researched the motors and found the Yellow Jackets weren't powerful enough, and we didn't want to gear them up because that would make things a lot more complicated.
- We looked through our motors for more powerful ones, researched the REV UltraPlanetary HD Hex motors, and chose them. We run them without gearboxes, so they can spin up to 6,000 RPM.
- At first the HD Hex motors were still too slow
Code Fix: Full Power
- After Josh left, he called with an idea: maybe the power wasn't turned all the way up in the code
- We checked and found two problems: the motors were named wrong in the Driver Station configuration and in the code, and the code was set up for a much slower motor
- Once we fixed that, a ball hit our 15-foot ceiling and ricocheted off really hard, so we had to turn it down
- We tried 0.5 power (a little too fast) and 0.25 (too slow), and settled on 0.4 as the sweet spot
- Switched the shooter motors to a mode that keeps their speed constant, so they don't slowly lose power as the battery drains
Hitting the Hive
- Tested on our mock-up hive
- We tested the shooter over and over again, iterating based on how accurate it was at different speeds and angles
- Still to work on: adjusting the servo so it loads the balls into the shooter properly
Springs: Not Needed
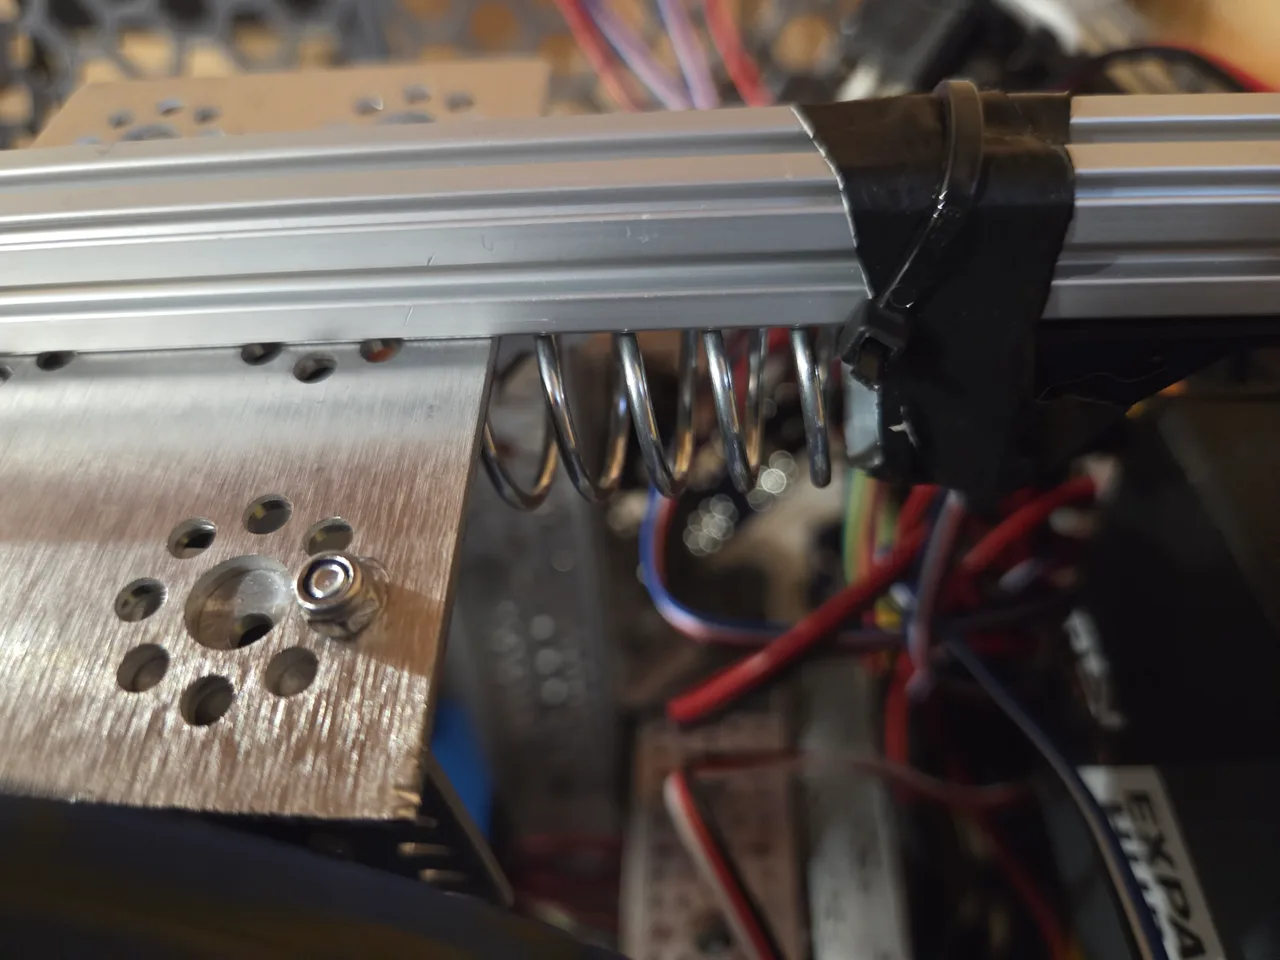
- Torin had a good idea to use springs to adjust the flywheels for the two different ball sizes
- It turned out we didn't need them: the wheels squish, so once the motors spin fast enough, the shooter handles both sizes of balls
Parts & Prints
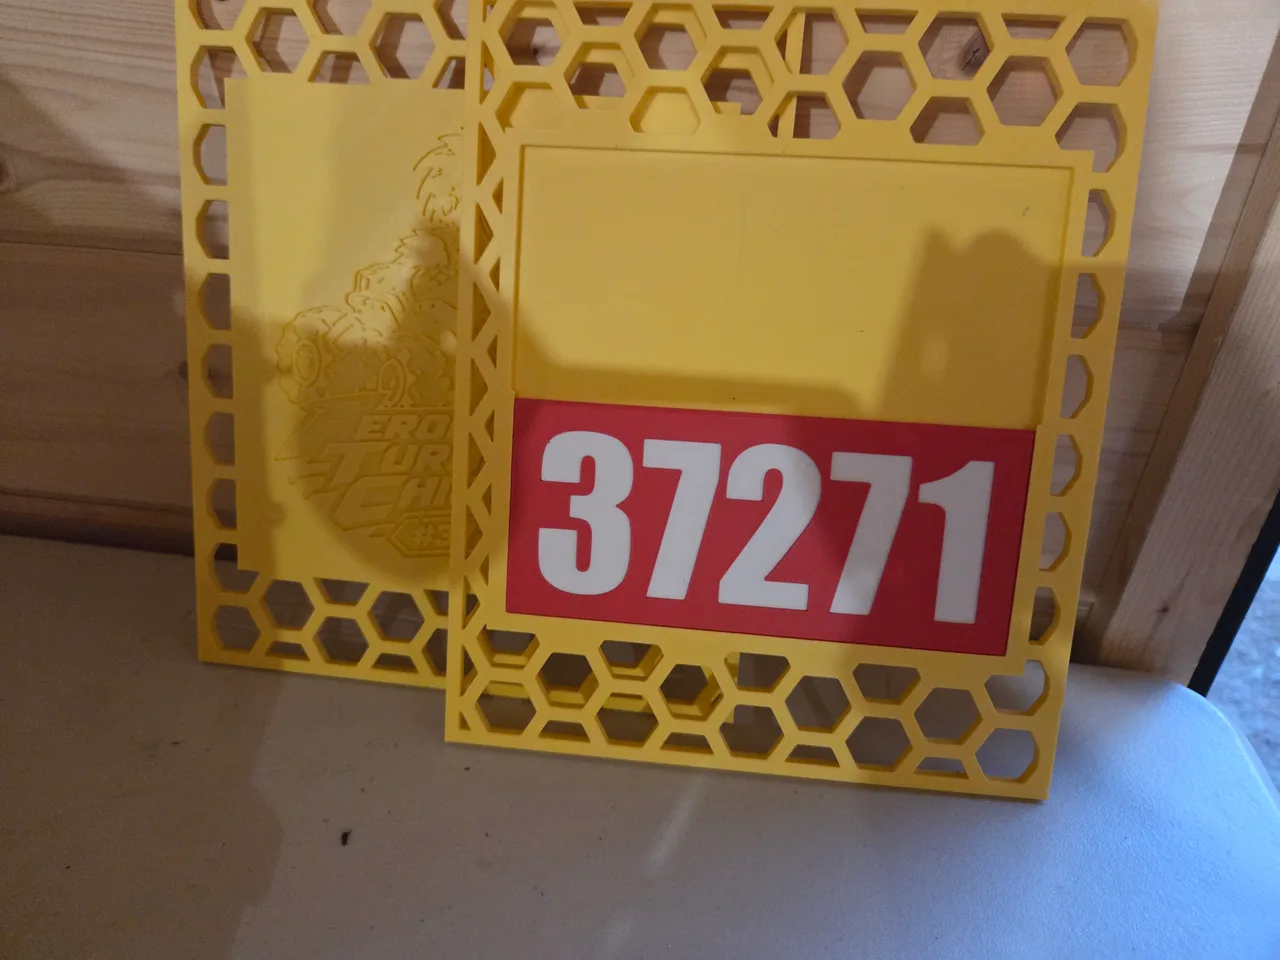
- Josh brought the red alliance number tiles (red background with white numbers) and a new print of the guide rails. We didn't install the guide rails today, but we may use them next week.
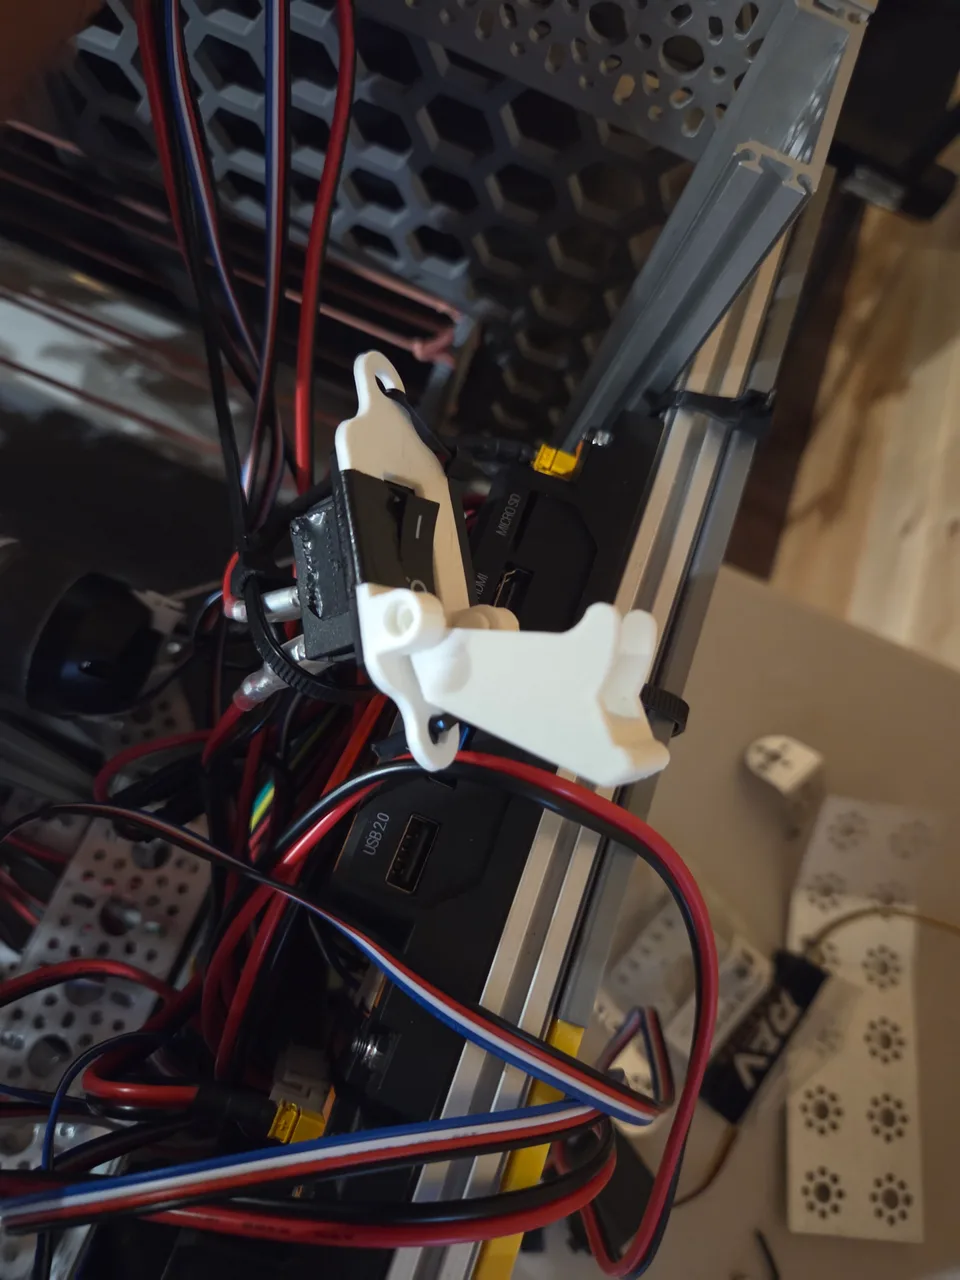
- The printed cover over the on/off switch keeps balls from bumping the robot off
Team Motto: ABC
We came up with an acronym to help us remember to charge everything: ABC: Always Be Charging!
Homework / Action Items
- Josh: print the panels with the logo on them, and color the logo to make it pop more
- Torin: start a checklist (with help from AI) of everything we need to do and bring for the scrimmage
- Sarah: edit this entry and upload it to the website, and make some changes to the previous entry
This notebook was created with the assistance of Claude AI and Handy dictation software.