October 7, 2026
Meeting Summary
Today was a really exciting day for us! It was the first meeting where we didn't take the robot completely apart. We fixed the drivetrain code so the robot finally drives and turns correctly, and we got the intake working: it picks up both sizes of balls quickly and easily. We brainstormed shooters and chose Torin's design for a continuous rotating catapult. We also set our priorities for the scrimmage, worked on the game field mock-ups, and researched how teams advance through the season.
Drivetrain: Fixed!
- Found that the yaw (turning) term was reversed in our mecanum drive math
- Found that our wheel directions were reversed
- After fixing the wheel directions and the turning direction in the mecanum drive math, the robot turned correctly
- Switched the motor ports back to their original setup
- We discovered we had forgotten to upload our code to the robot, which is part of why earlier fixes didn't seem to work
- Did several test drives
Intake: Working
- Got the Core Hex motor running and hooked up the chain
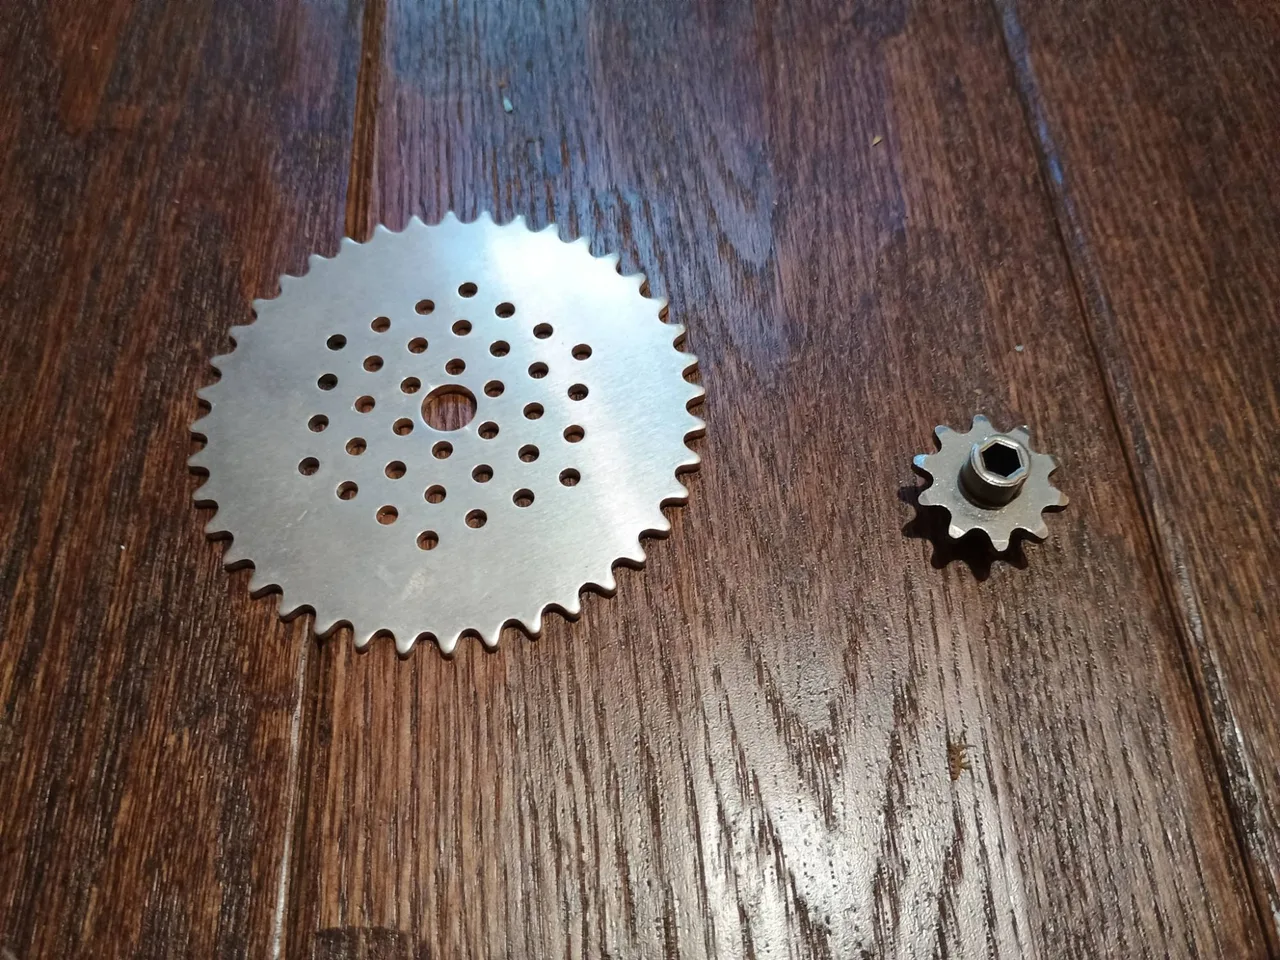
- The intake wasn't spinning fast enough, so we put a bigger gear on the motor to speed it up
- Fixed the chain, which was too loose
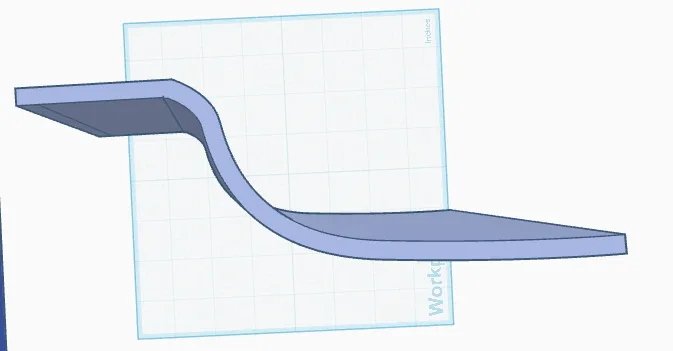
- Installed the new ramp (designed by Josh, printed by Sarah)
- Flipped the intake motor direction
- Result: when we dumped a bunch of balls in front of it, the intake picked up both sizes quickly and easily
- The intake also reverses quickly, so the driver can spit out the other alliance's balls
- We still need stronger rubber bands
- Future idea: make the intake automatically sense and reject the wrong color ball. For the scrimmage, a driver will control the intake and shooter manually.
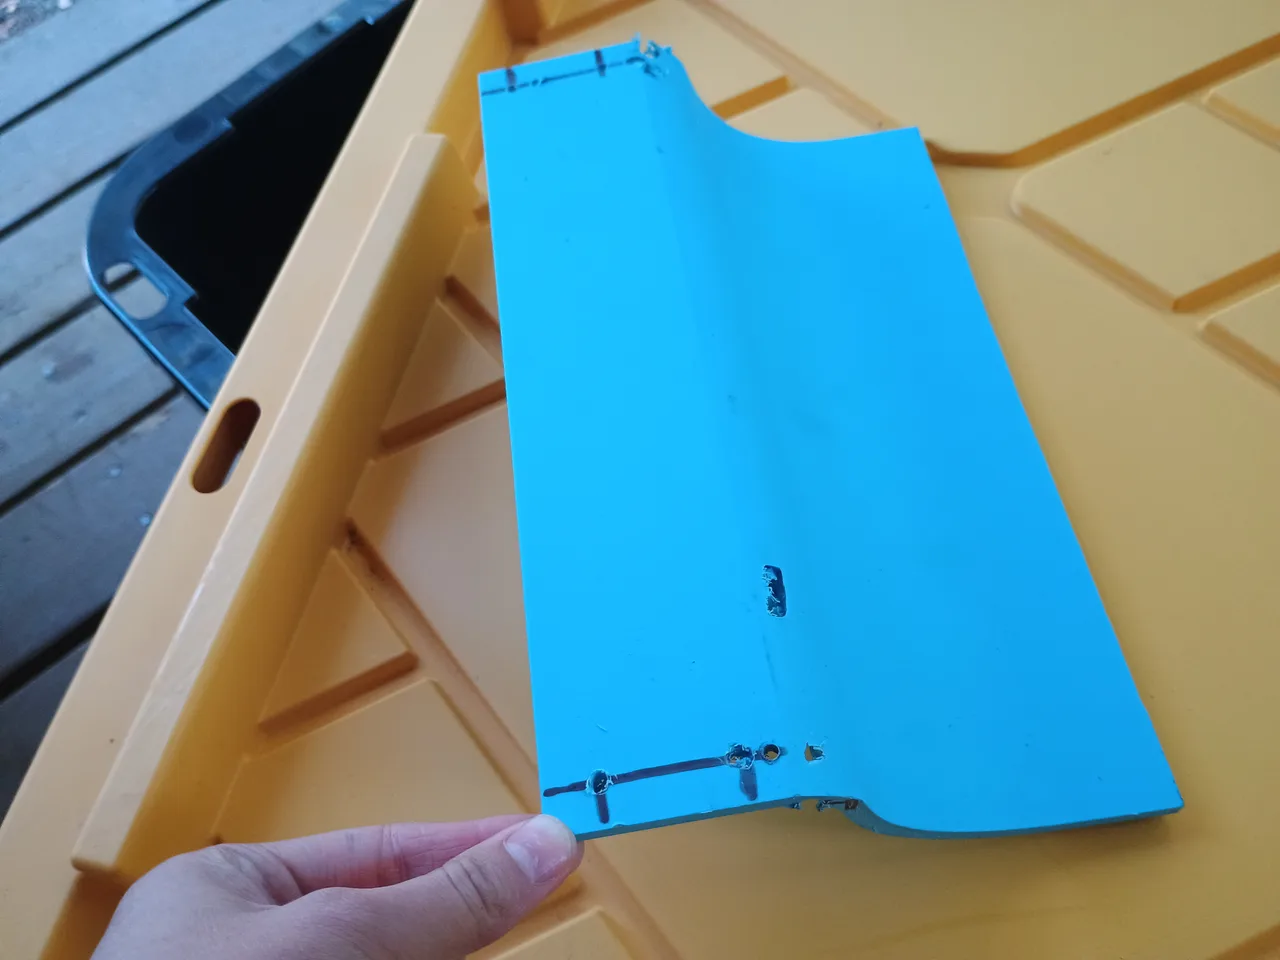
Josh's latest ramp design in TinkerCAD:
Shooter Research & Design
- Torin researched shooters before this meeting, and we researched more together: what other teams used for shooters last season, what they're using this season, and how teams are handling the flower so far
- We discussed only intaking and shooting pollen, but decided to intake both kinds of balls
- We decided a catapult shooter would be best
The problem with most catapults:
- They're slow, because you have to pull them back (cock them) before every shot
- They can't rotate, so they can't track the hive and shoot while the robot is driving
- Their firing speed can be inconsistent
Torin's solution: a continuous rotating catapult
- Two catapult arms, 180° apart in one flat plane, mounted on a single hex shaft in the center
- Rubber bands are twisted around the hex shaft by a motor that isn't attached to the shaft
- The motor runs continuously, winding the rubber bands tight
- A servo releases an arm to fire. The catapult spins, and the next arm swings into place.
- A servo then stops the next arm while the motor winds the rubber bands up again
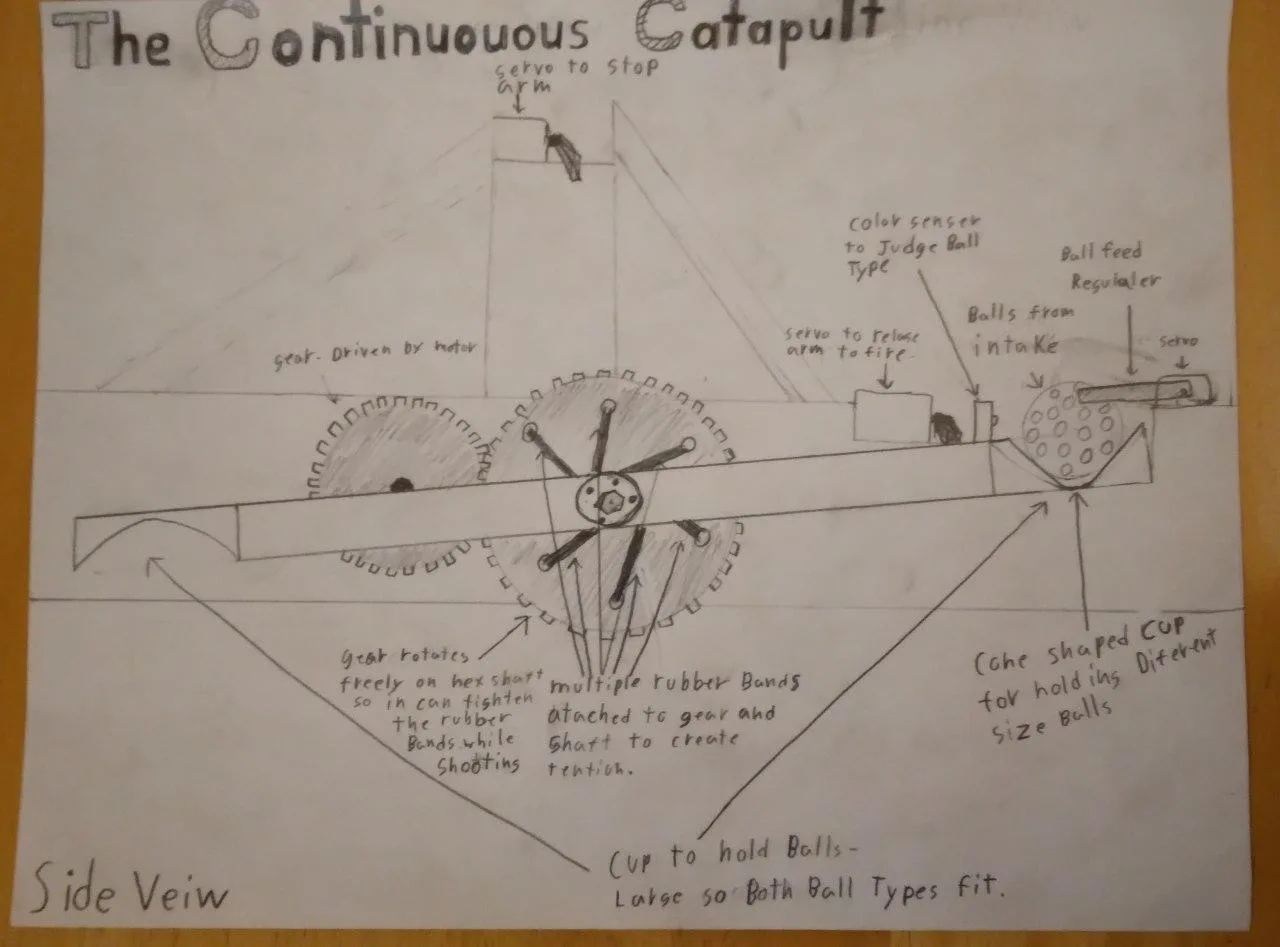
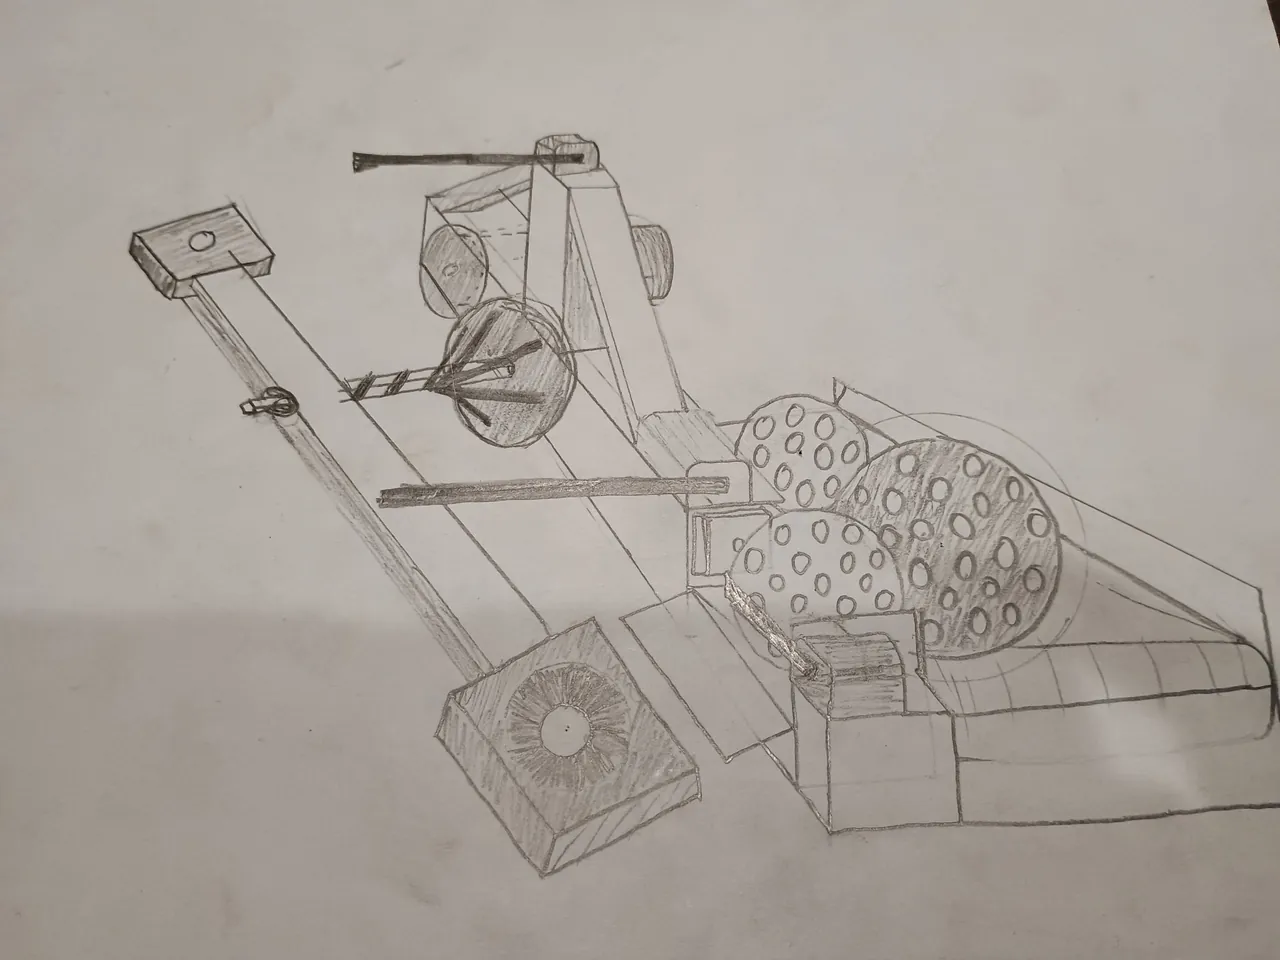
Plan: we'll use our flap idea (from entry 04) together with Torin's continuous rotating catapult and test them at the scrimmage to see how they compare to rotating turrets. We may swap the catapult for a rotating turret later.
Priorities for the Scrimmage
- Before the scrimmage (October 24): focus on the shooter and intake
- Later: the rotating turret and AprilTags
- After the scrimmage: sensors and autonomous
Intake Gears
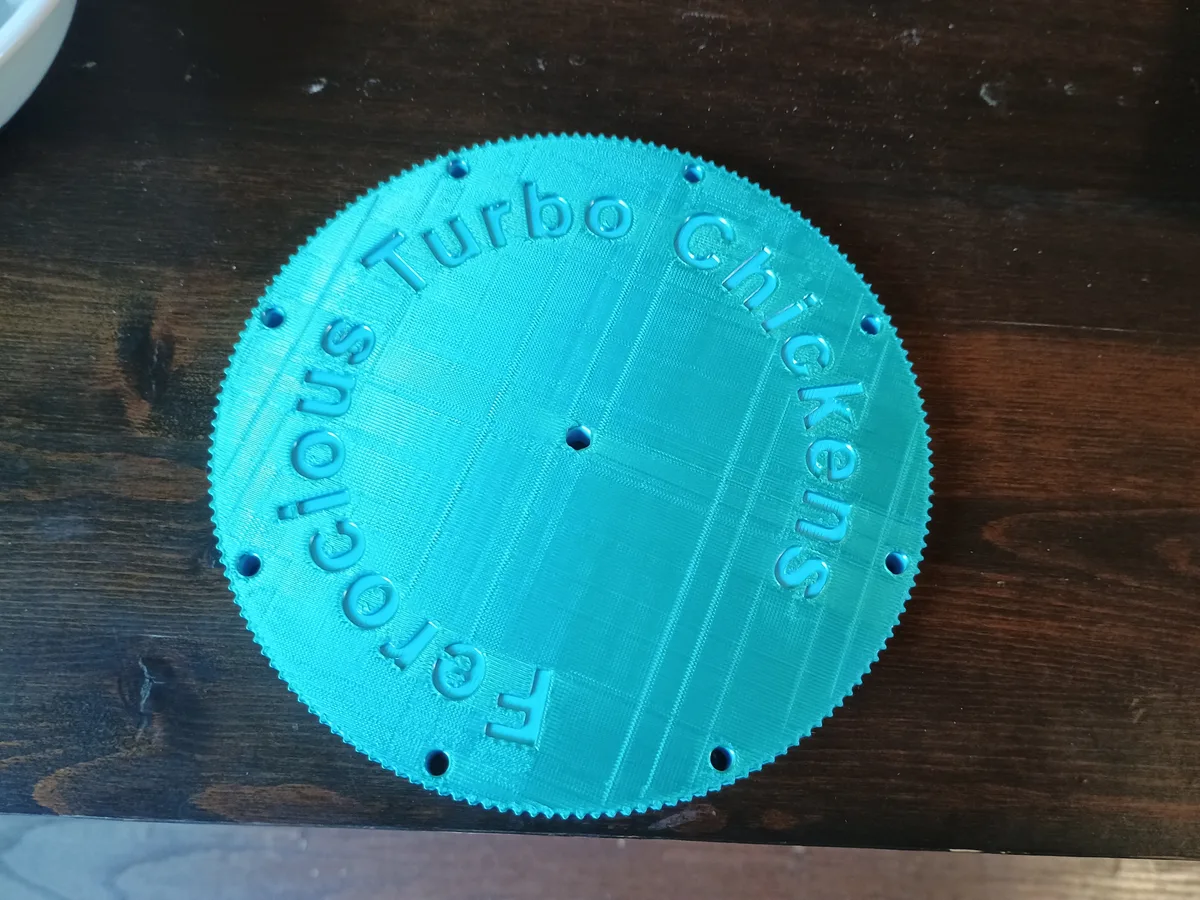
- Sarah printed two gears, but accidentally printed the big version instead of the redesigned small version
- Sarah is reprinting them at the original diameter
Game Field Mock-Ups
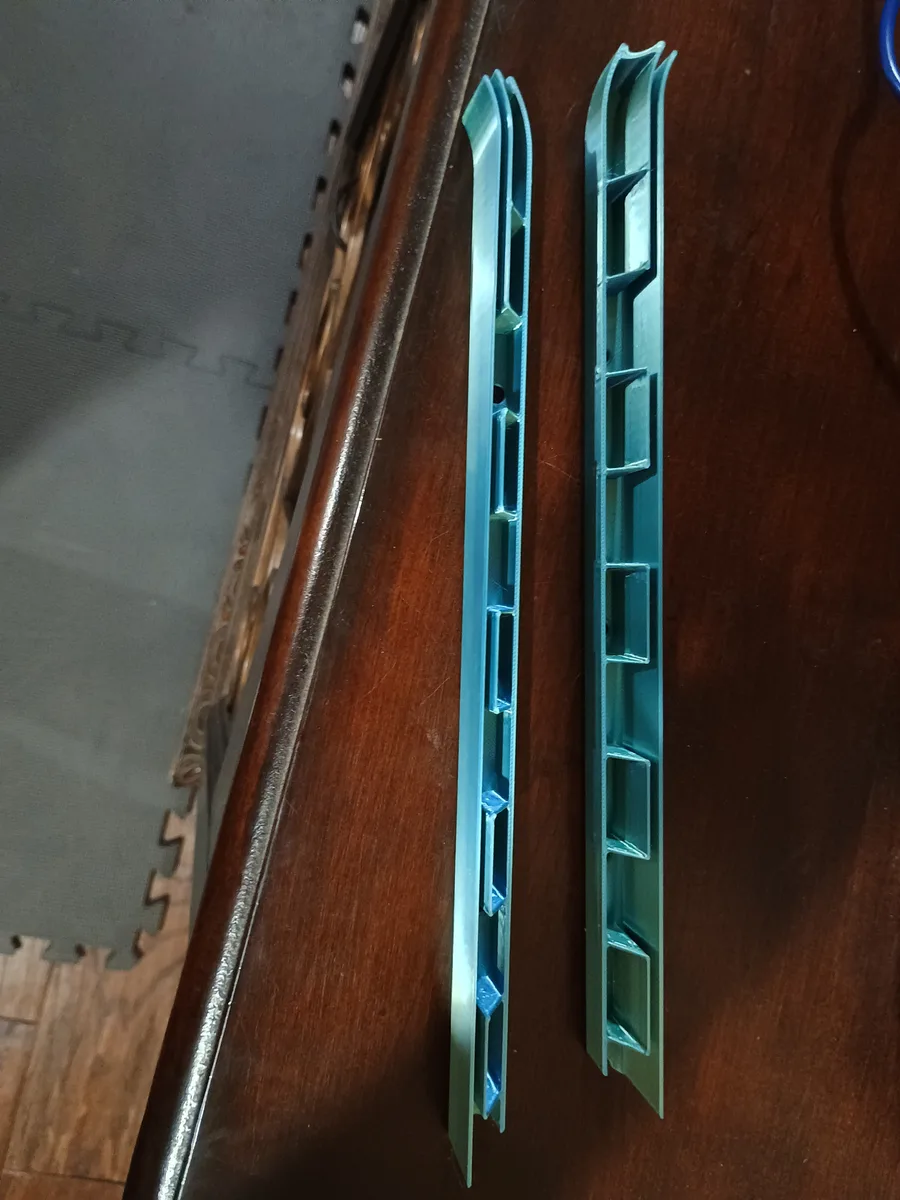
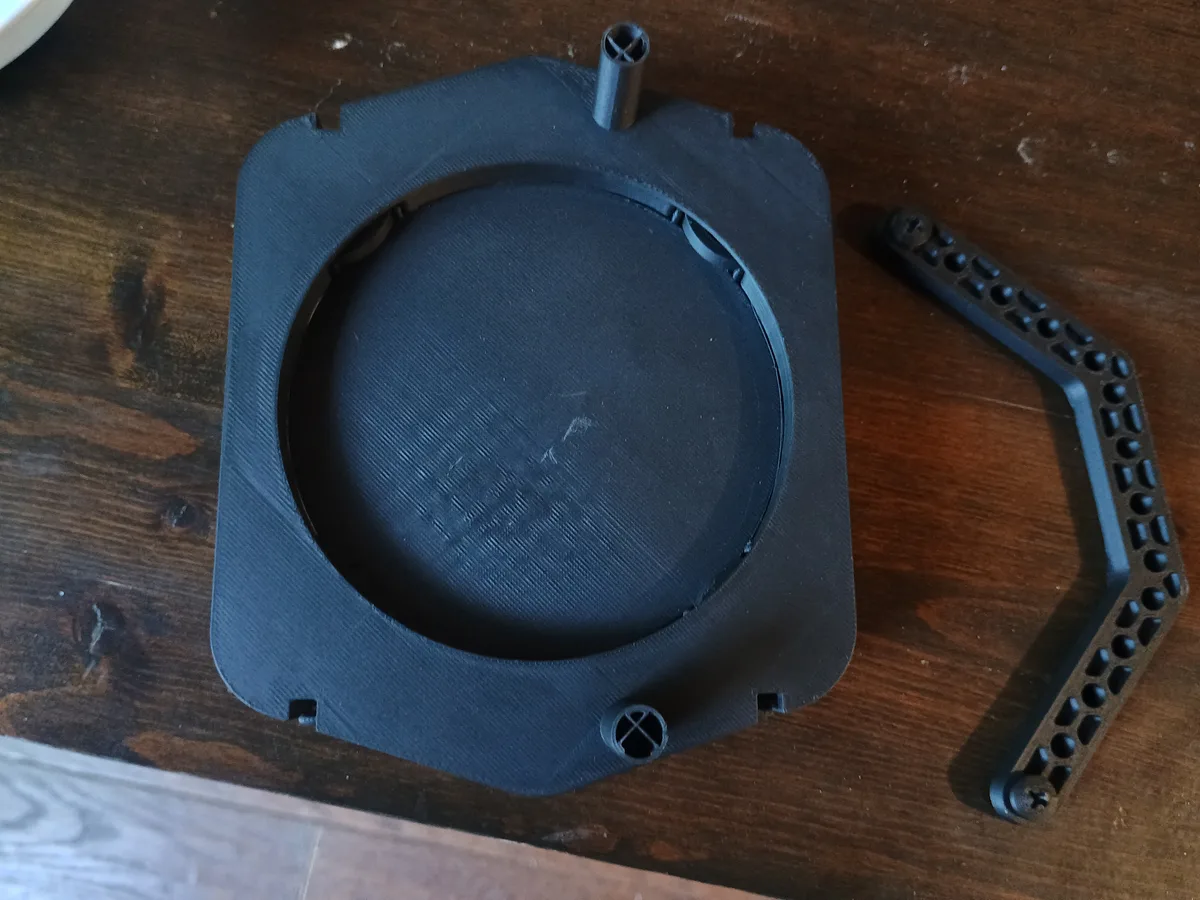
- Torin found CAD files for the hive, so we're 3D printing plastic brackets to build it, and we printed our first hive frame parts
- Torin planned to bring aluminum for the hive today, but found he didn't have the right aluminum bars. He hopes to bring them Monday.
- Josh printed part of the flower, but it came out wrong because of a problem in the file. He'll reprint it correctly.
- On Monday, we plan to set up the whole arena except the parts we don't have (like the hive), hopefully with mock-ups of the hive and flower, and practice driving
Research: Advancement
- Researched how teams advance from the regional championship to the state championship to Worlds, and how Premier events work
Outreach & Planning
- Sarah delivered our schedule flyer to Columbia Bank
- Our coach announced an all-day robotics day on Monday, October 12, from 9 AM to 5 PM, with lunch provided
- Still to do, hopefully Monday when our main coach is back: call Cascade Community Credit Union to thank them for their donation and ask if we can use their logo, and get PVC pipe and more heavy-duty rubber bands
Coming Up Soon
- Code the shooter once it's built (Sarah)
- Read through and completely understand our code, so we can truly explain it to the judges (Sarah)
- Work on our judging presentation and engineering portfolio
- Design the flap and work out how it will function
- Check whether there have been any rule updates since the start of the season
Homework / Action Items
- Torin: start building the hive mock-up, and provide Sarah with a sketch of his shooter idea for the website
- Josh: redesign the ramp and send it to Sarah to print (her printer has a bigger bed); print the corner brackets for the hive; reprint the flower part; and send Sarah screenshots of the auger and ramp versions for the website and portfolio
- Sarah: send Josh a photo of the roughly cut and adjusted ramp so he can see what to redesign; print the redesigned ramp in black, white, or gray; print part of the hive frame; and reprint the gears in the small version
- Someone: call Cascade Community Credit Union to thank them and ask if we can put their logo on our website, shirts, and banner
- Someone: check for rule updates since the start of the season
This notebook was created with the assistance of Claude AI and Handy dictation software.