ENTRY
09
September 30, 2026
Rebuild, Intake Prototype & Drive Troubleshooting
Meeting Summary
We rebuilt the frame so the ramp would line up and attached the ramp and the rubber band intake. After a few adjustments, the intake grabbed balls well when we spun it by hand. We made two design changes: a wider intake that no longer needs the side screws, and a Core Hex motor for the intake chain drive. Sarah rewrote the drive code, and our test drive showed that the motors are plugged into the wrong ports and the wheels are mounted incorrectly.
Build: Frame Rebuild
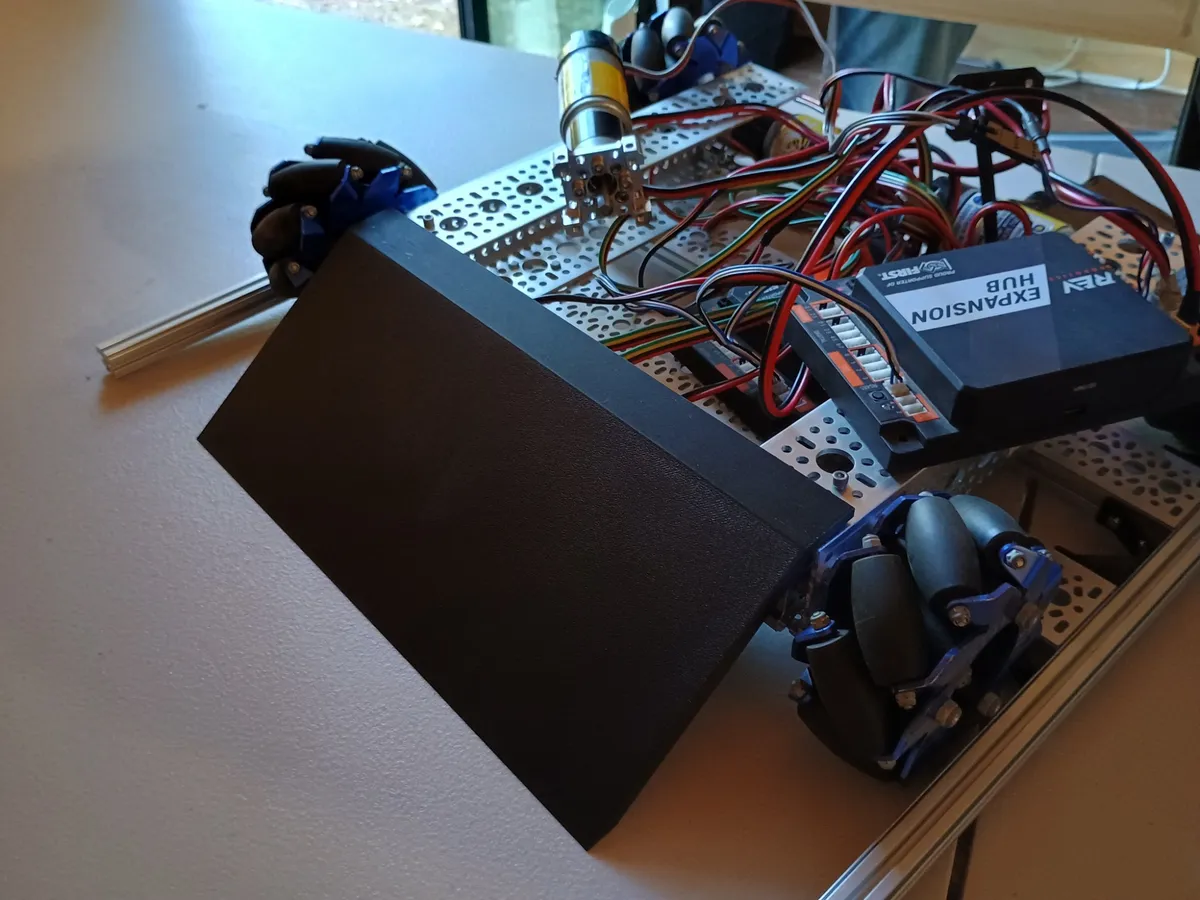
- Took the robot apart again because the ramp didn't line up with the mounting holes and our beams weren't long enough
- Found longer beams, cut them to length, put everything back together, and attached the ramp
- Problem: the beams were cut too short, so we can't put in all four screws on the motors. We need new, longer bars to secure the motors and make the frame stronger.
Build: Intake Prototype
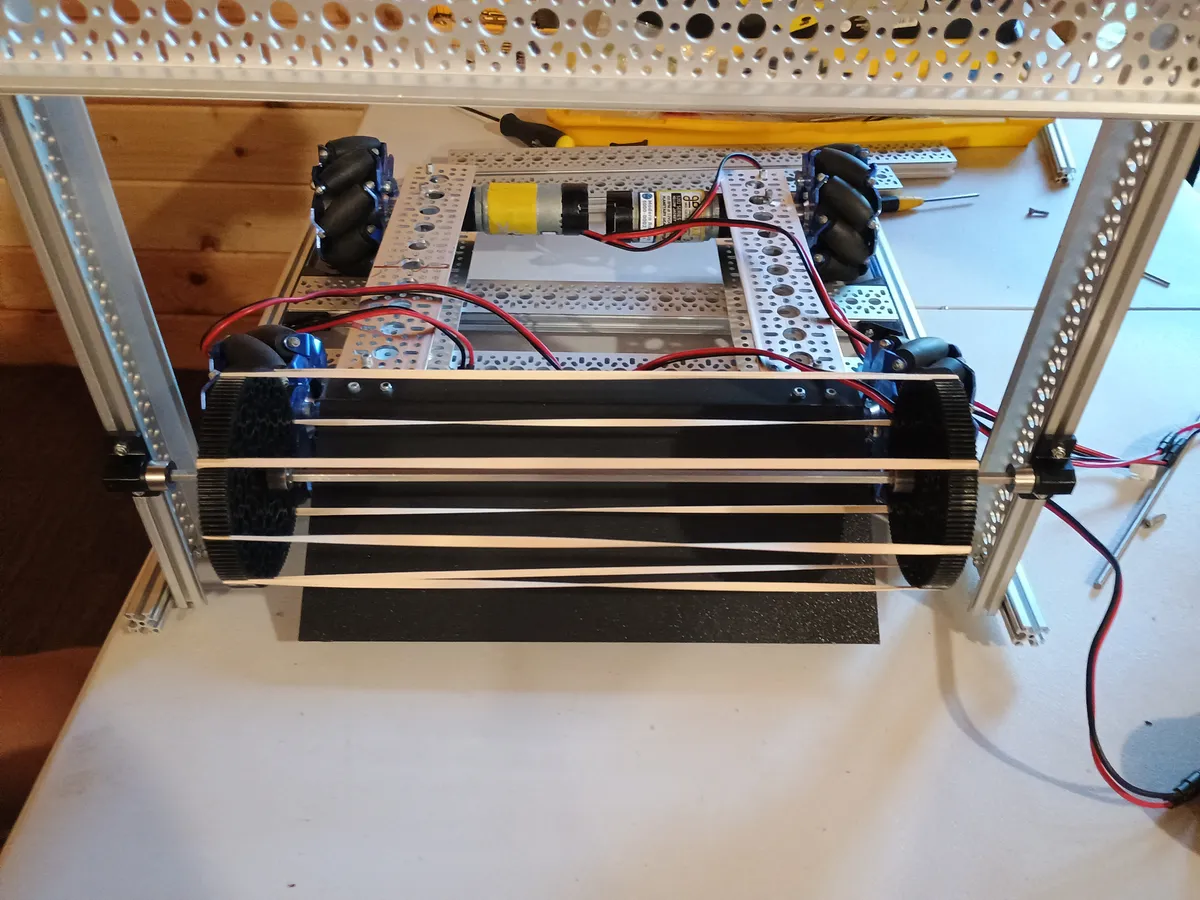
- Assembled the rubber band intake. It doesn't have a motor yet, so we spun it by hand to test it with pickleballs.
- After a few adjustments, it grabs the balls well:
- Moved the intake lower
- Cut the ramp (it's just a prototype, so we cut it to see how it would work)
- Made the ramp angle steeper
- Started attaching the intake to the robot, and it worked great
Design Changes
- No side screws for the intake: we made the rubber band intake a lot wider, so we no longer need screws to feed balls into it. Instead, we'll use a screw to carry the balls up to the turret shooter.
- Intake motor: we switched from a Yellow Jacket motor to a Core Hex motor for the intake chain drive. We couldn't find the right gears for the Yellow Jacket's shaft, but we have the correct gears for the Core Hex motor's hexagonal shaft.
- 3D printing: we printed this ramp at 100% infill. We'll try 90% next time.
Code & Electronics
- Added the Expansion Hub to the Driver Station configuration
- Sarah started the drive code over from scratch, and we think the code is now fixed
- Our test drive showed two hardware problems: the motors are plugged into the wrong ports, and the wheels are mounted incorrectly. The robot drives backward when it should go forward (and vice versa), and turning is still wrong.
- We need to decide whether to fix this in the code or swap the motor ports
Planning & Logistics
- The game balls and AprilTags will arrive on Monday
- We need PVC pipe to build mock-ups of the flowers
- We need to discuss meeting a third day each week, or holding an all-day session once or twice a month
Homework / Action Items
- Josh: redesign the ramp to be ½" shorter and ¼" narrower, with a steeper angle so it still reaches the same height, and a longer flat mounting section for the drill holes. Send it to Sarah to print.
- Josh: reverse the screw's direction so it carries the balls up to the shooter properly
- Sarah: print the flower parts Torin sent and the new ramp, send the code to Torin, and make a sheet of our competition and event schedule for Columbia Bank
- Torin: look through the code, and get new, longer bars to replace the beams that were cut too short so the motors can be secured with all four screws
- Everyone: brainstorm ideas as needed
This notebook was created with the assistance of Claude AI and Handy dictation software.