ENTRY
07
September 23, 2026
Chassis Redesign & Intake/Shooter Brainstorming
Meeting Summary
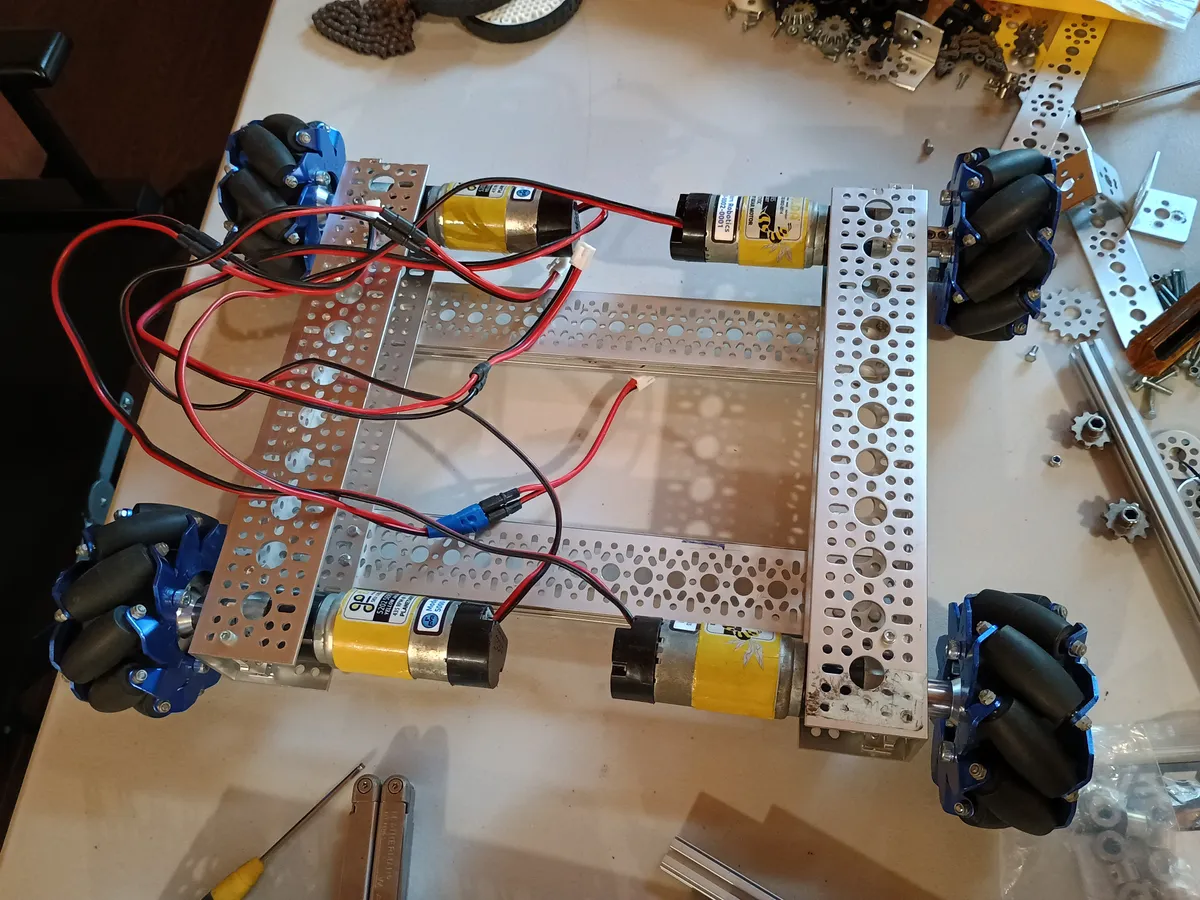
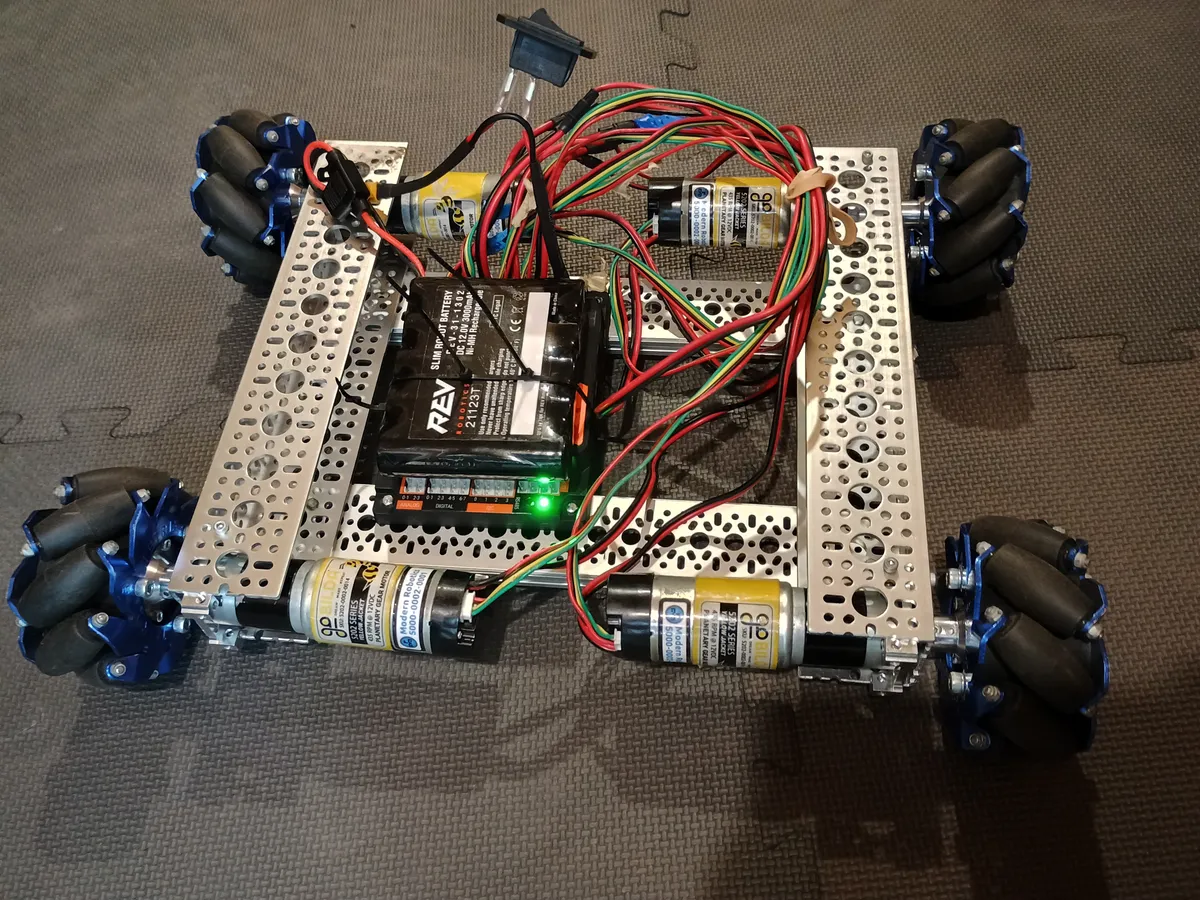
We tore down the chassis from our last meeting and rebuilt it with a standard mecanum wheel layout and a smaller wheelbase. By the end of the meeting it was fully built and we test drove it. We brainstormed intake and shooter designs, watched videos of top FTC robots from last season for ideas, organized our tools and parts, and launched our team website.
Build: Chassis Redesign
- Took apart the previous design, which used a straight beam across the front
- Rebuilt it with a standard mecanum wheel layout, instead of our previous flipped design where the wheels faced sideways relative to the direction the robot drove forward
- Chose a smaller wheelbase so the drive motors stay out of the way of our intake
- The robot is currently wider than it is long, and we plan to have a ramp out the front for the intake
- Finished the chassis, got it running, and test drove it
Code: Test Drive Results
- Driving forward/backward and strafing now work correctly
- Turning is reversed and still needs to be fixed
Intake Ideas
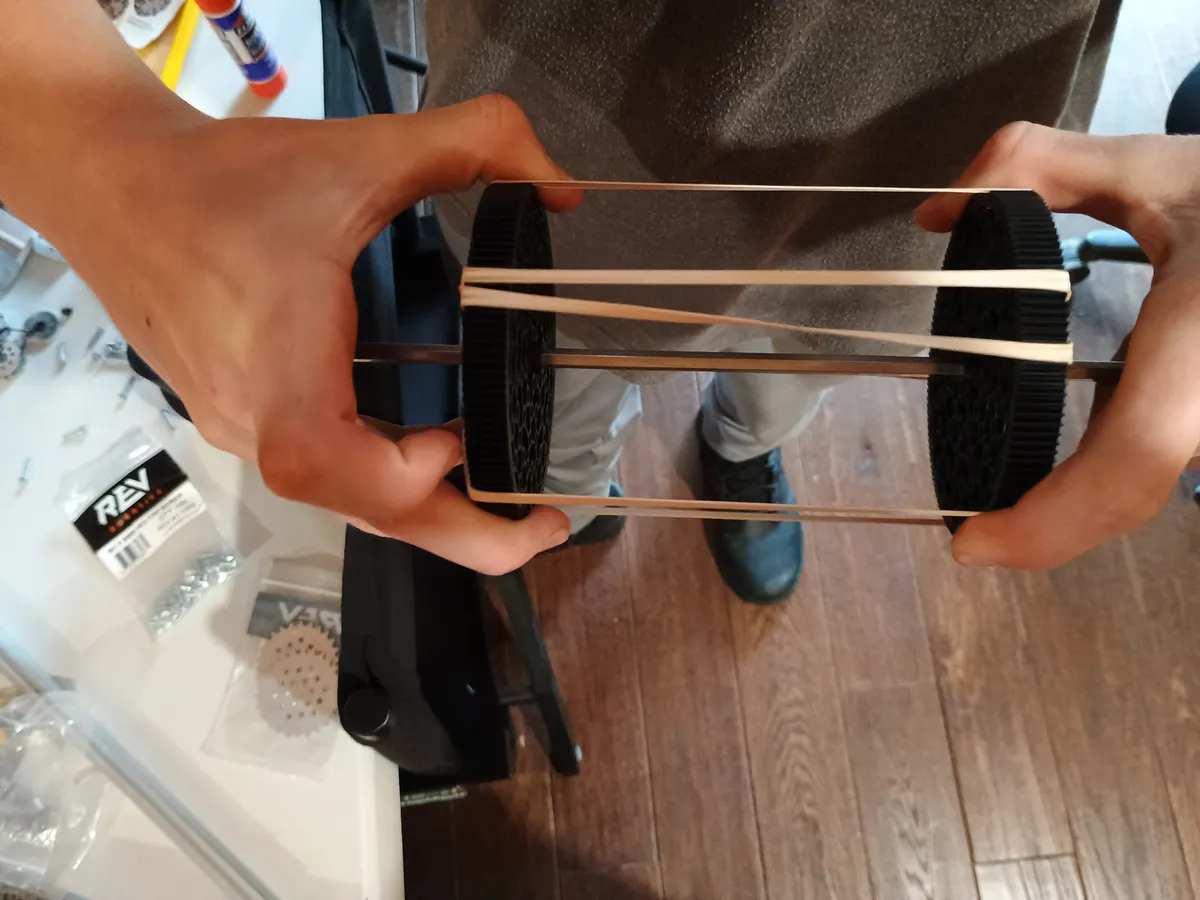
- Main intake: sturdy rubber bands stretched across a roller to grab the balls
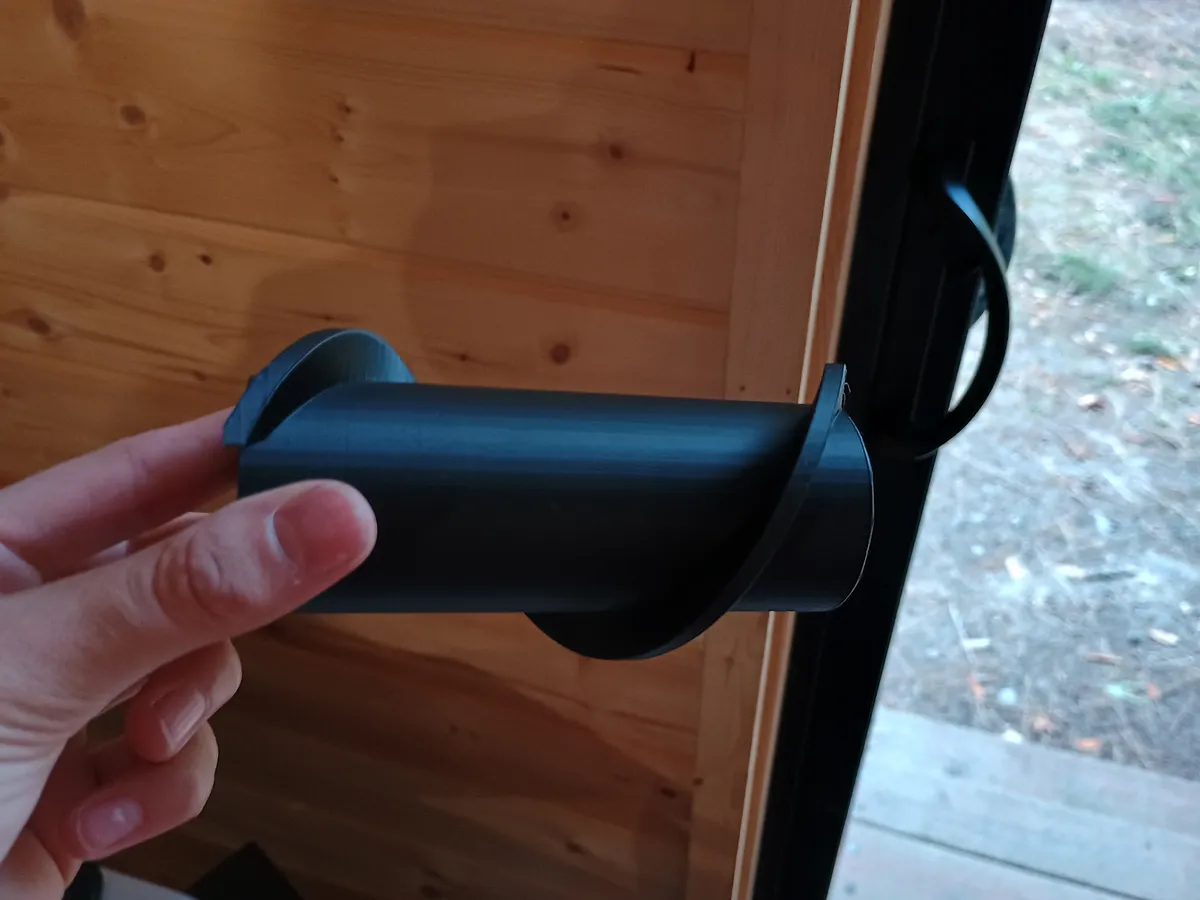
- Side feeders: screws (augers) on each side of the main intake to pick up balls across a wider area and feed them into the rubber band mechanism
- From the intake, the balls would move into the shooter
- Josh brought 3D-printed screw prototypes to the meeting
Shooter Ideas
- Discussed several types of shooters
- Leaning toward a rotating turret shooter
Research: Last Season's Top Robots
We watched videos of leading FTC robots from last season. Ideas we took away:
- A rotating turret shooter
- Feeders on either side of the main intake to guide balls in
- Side and back guards (plates) around the robot
We also saw Limelight cameras on these robots.
Design Decisions
- No gearboxes or chain drives: we decided to avoid them to reduce the number of things that could go wrong
- Vision: we want to get a Limelight camera
- Game pieces: for now we are using pickleballs to roughly estimate sizes and fit until we have balls that match the game specification
Organization & Outreach
- Organized our boxes of tools and robot parts from last year's prep-course kit
- Sarah, with the assistance of Claude, built and launched our team website, ferociousturbochickens.com, adding the home page, engineering notebook, resources page, and fundraising flyer, and made numerous edits
- Set up GitHub to back up every version of the website
Homework / Action Items
- Everyone: brainstorm intake and shooter ideas
- Josh: redesign the 3D-printed screws that feed balls into the main intake
- Sarah: fix the reversed turning in the drive code, keep working on the website, and write this notebook entry
Next Meeting
- Start building the shooter and intake
This notebook was created with the assistance of Claude AI and Handy dictation software.